Projects
 2025
Gateway State Estimation via Moon-Horizon Optical Navigation
Gateway State Estimation via Moon-Horizon Optical Navigation
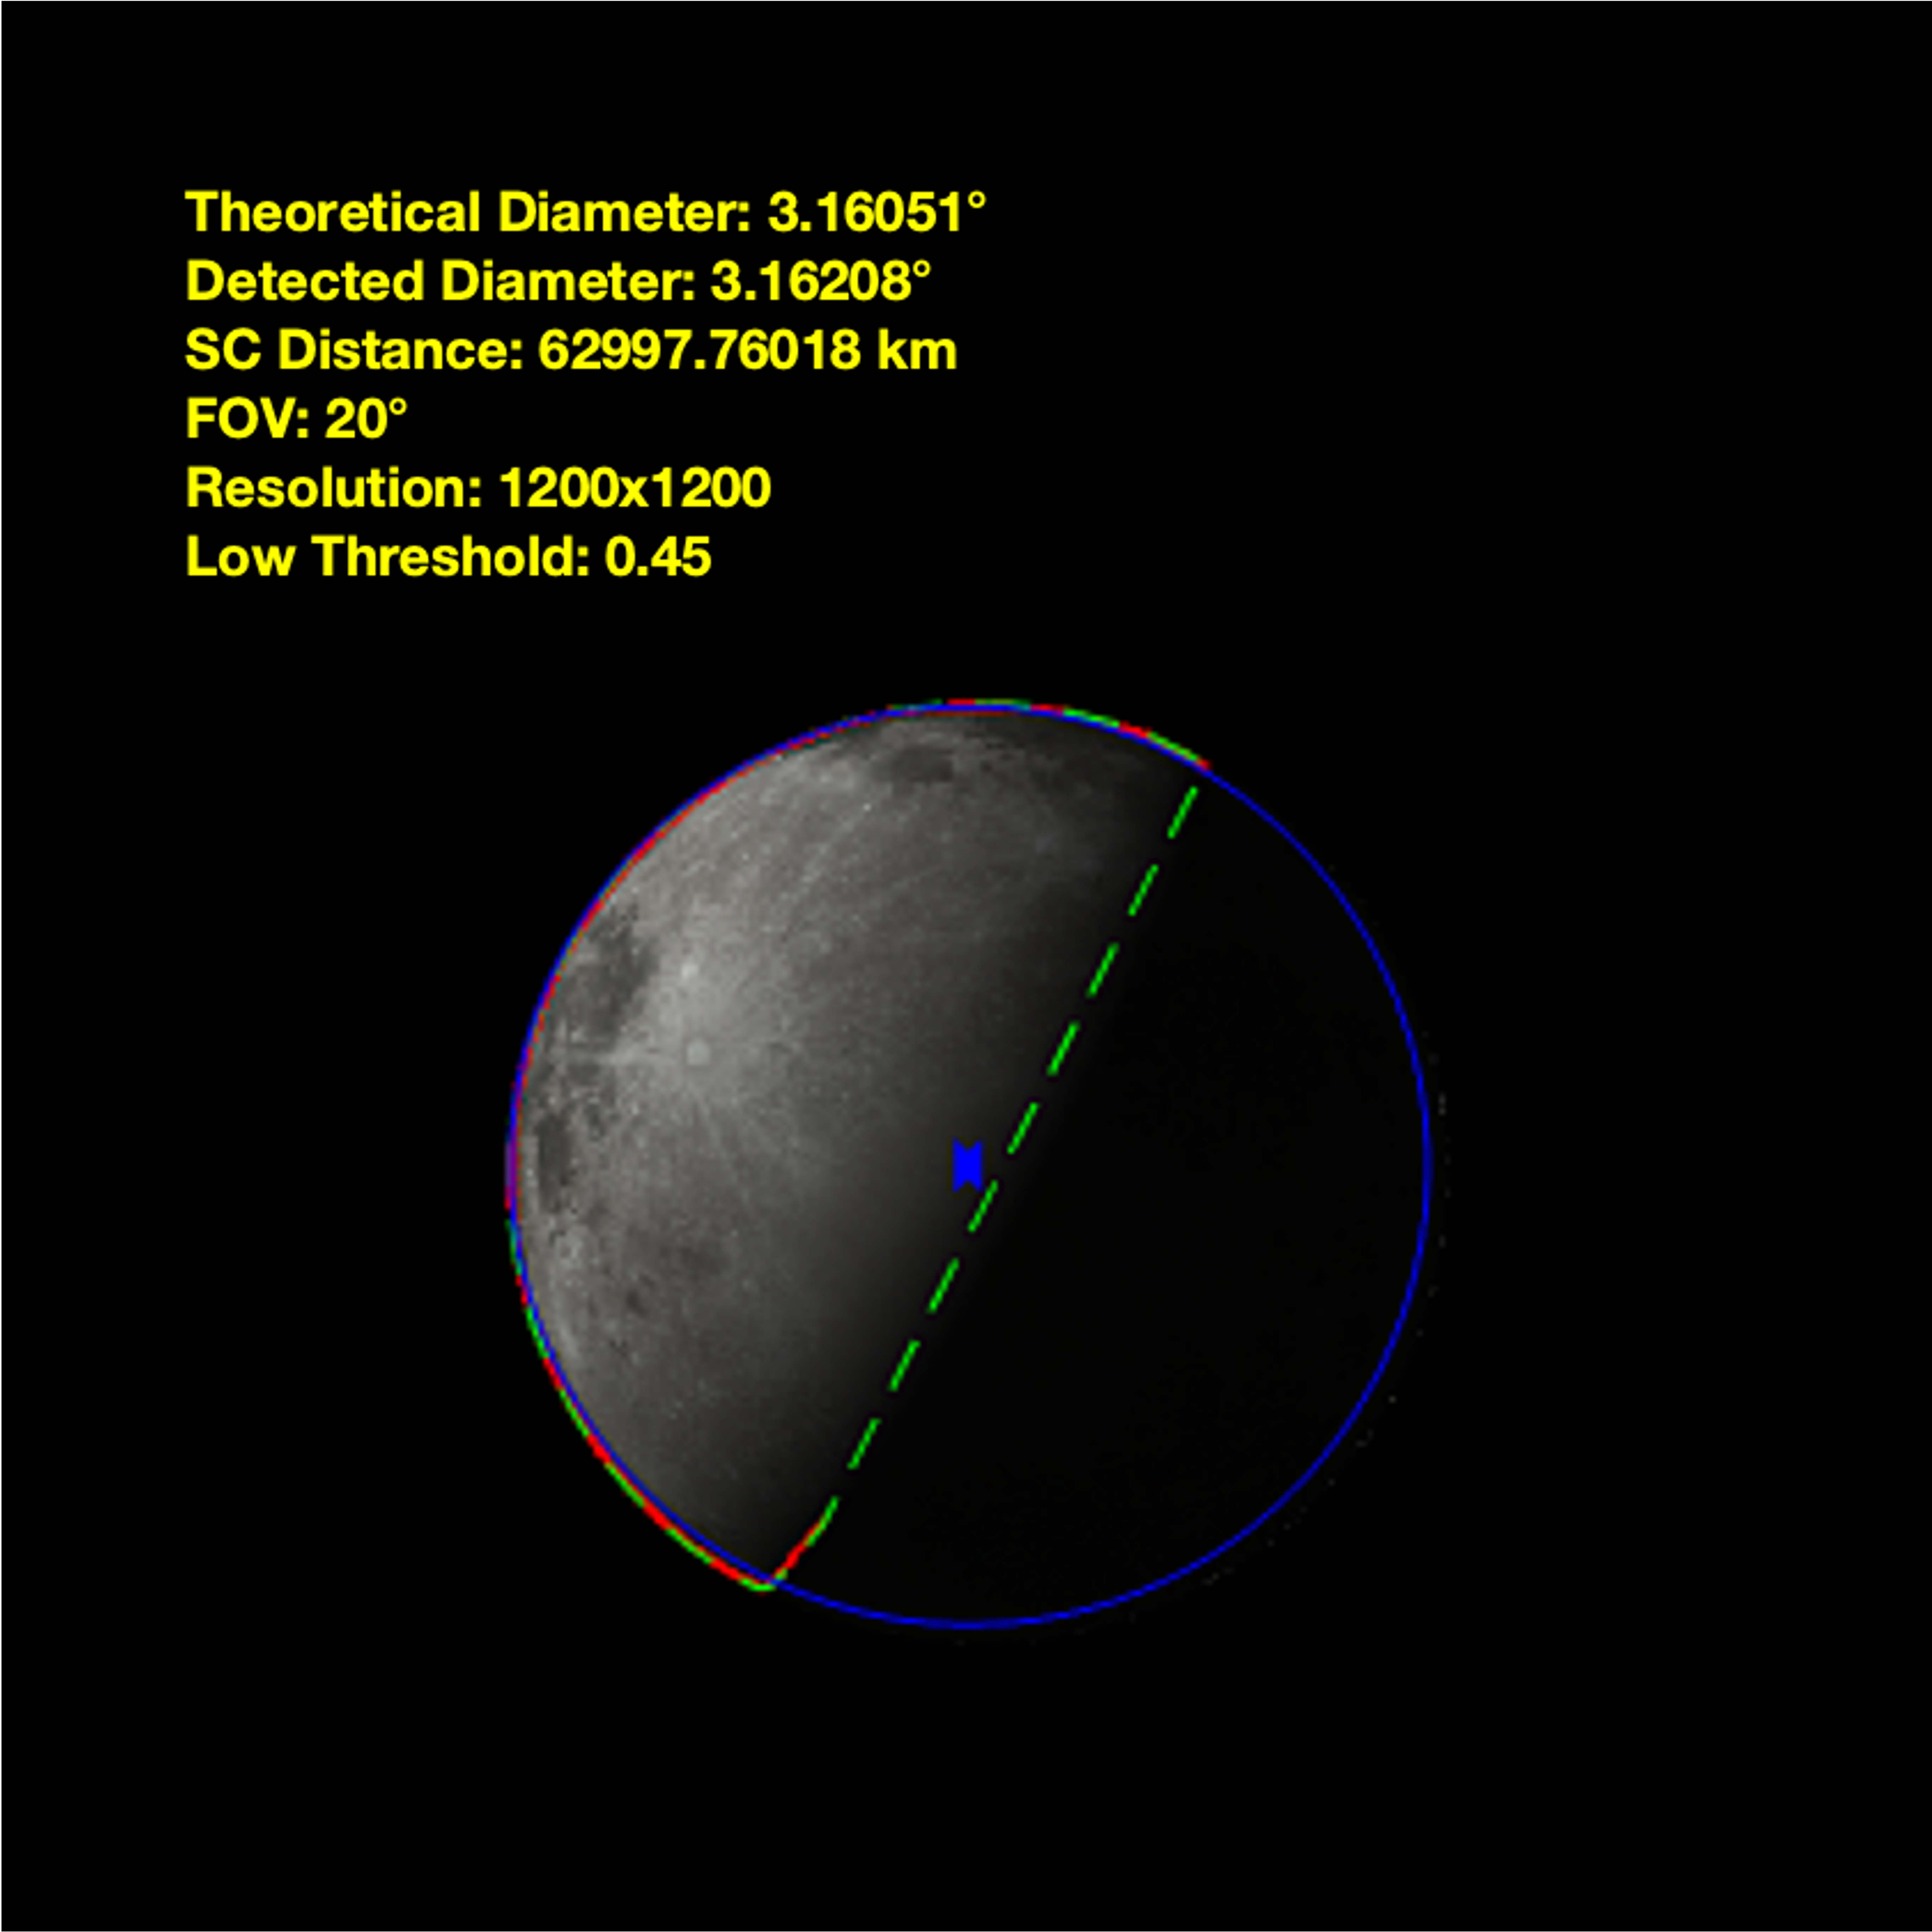
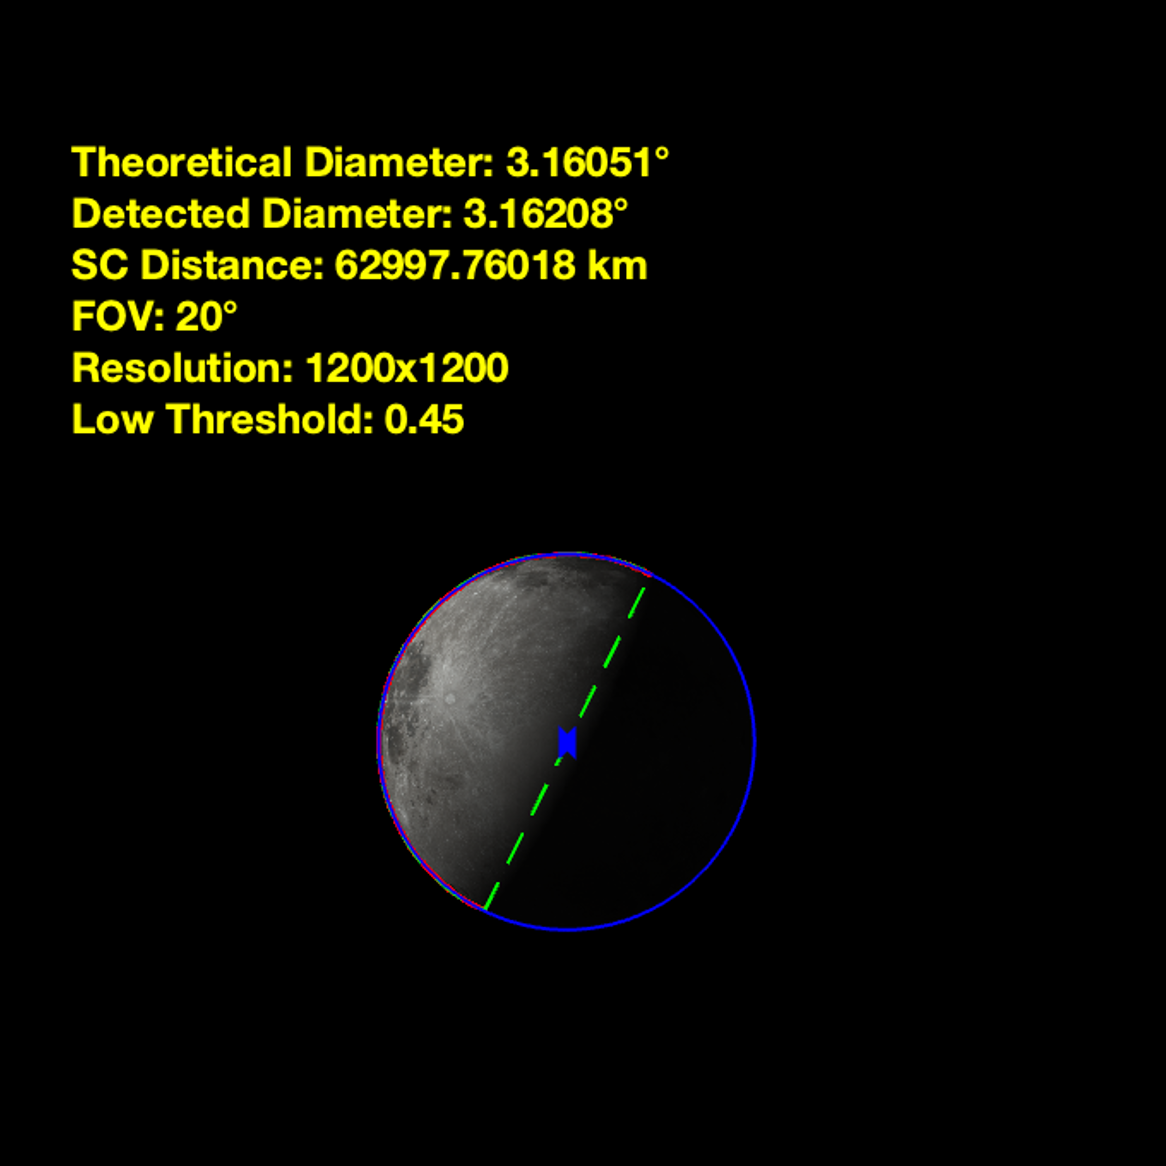
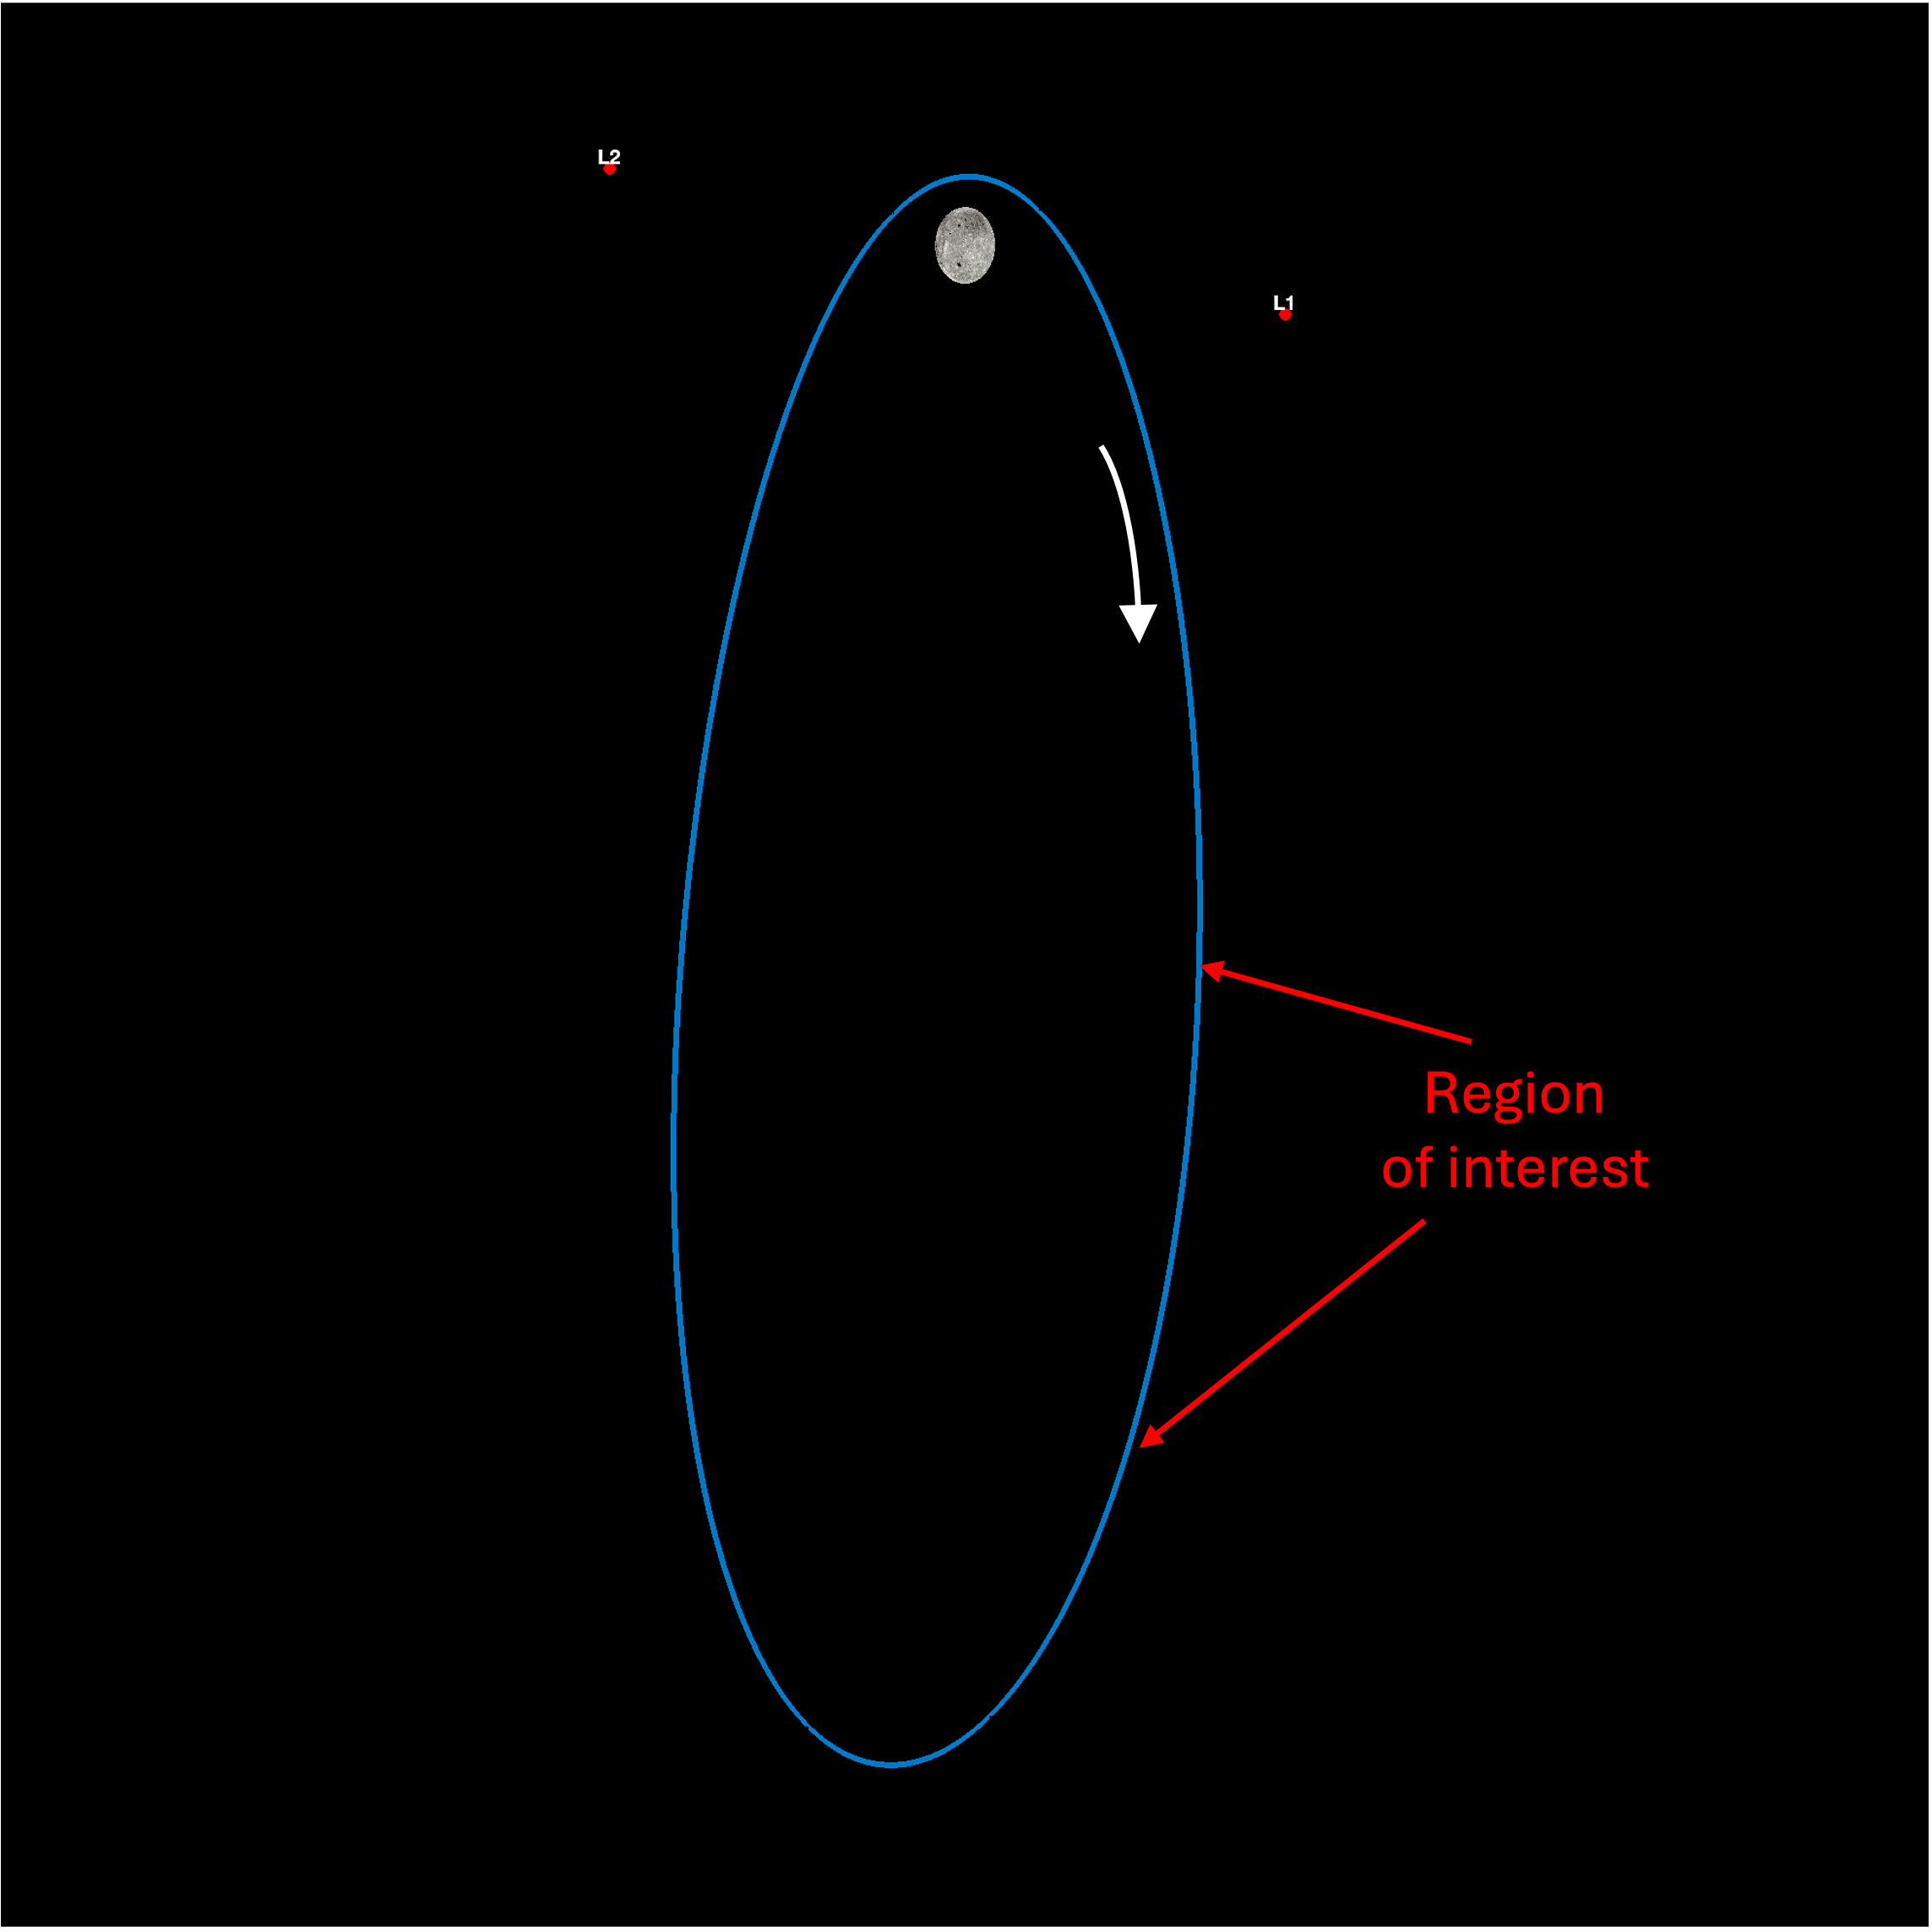
Estimated Gateway state in NRHO using only Moon-horizon imagery with CR3BP dynamics, reducing dependence on ground tracking.
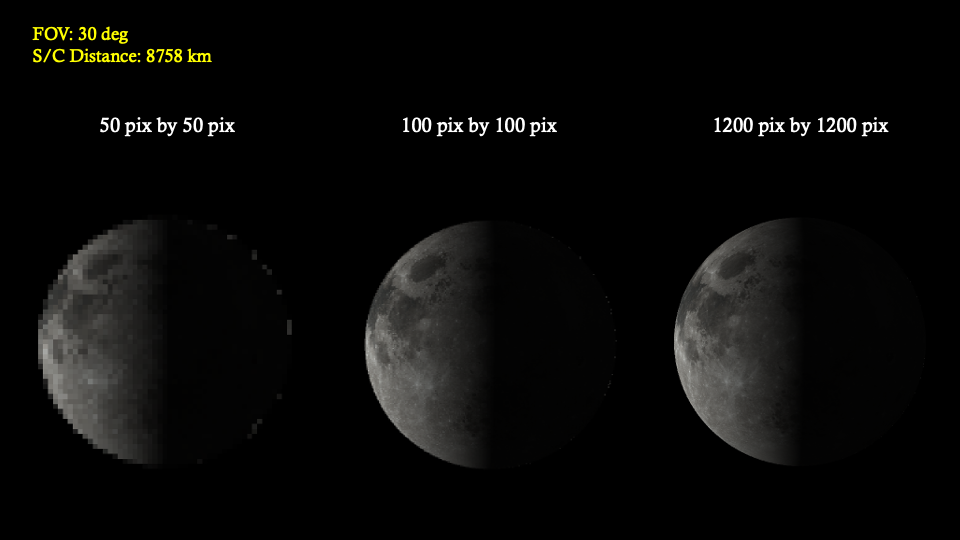
- Built a synthetic imaging pipeline with limb detection and conic fitting for navigation measurements.
- Implemented Christian-Robinson OPNAV with EKF/UKF filtering.
- Achieved km-level position and m/s-level velocity accuracy in cislunar multi-body regimes.
Completed as part of AAE590 PET (2025) at Purdue University.
 2024
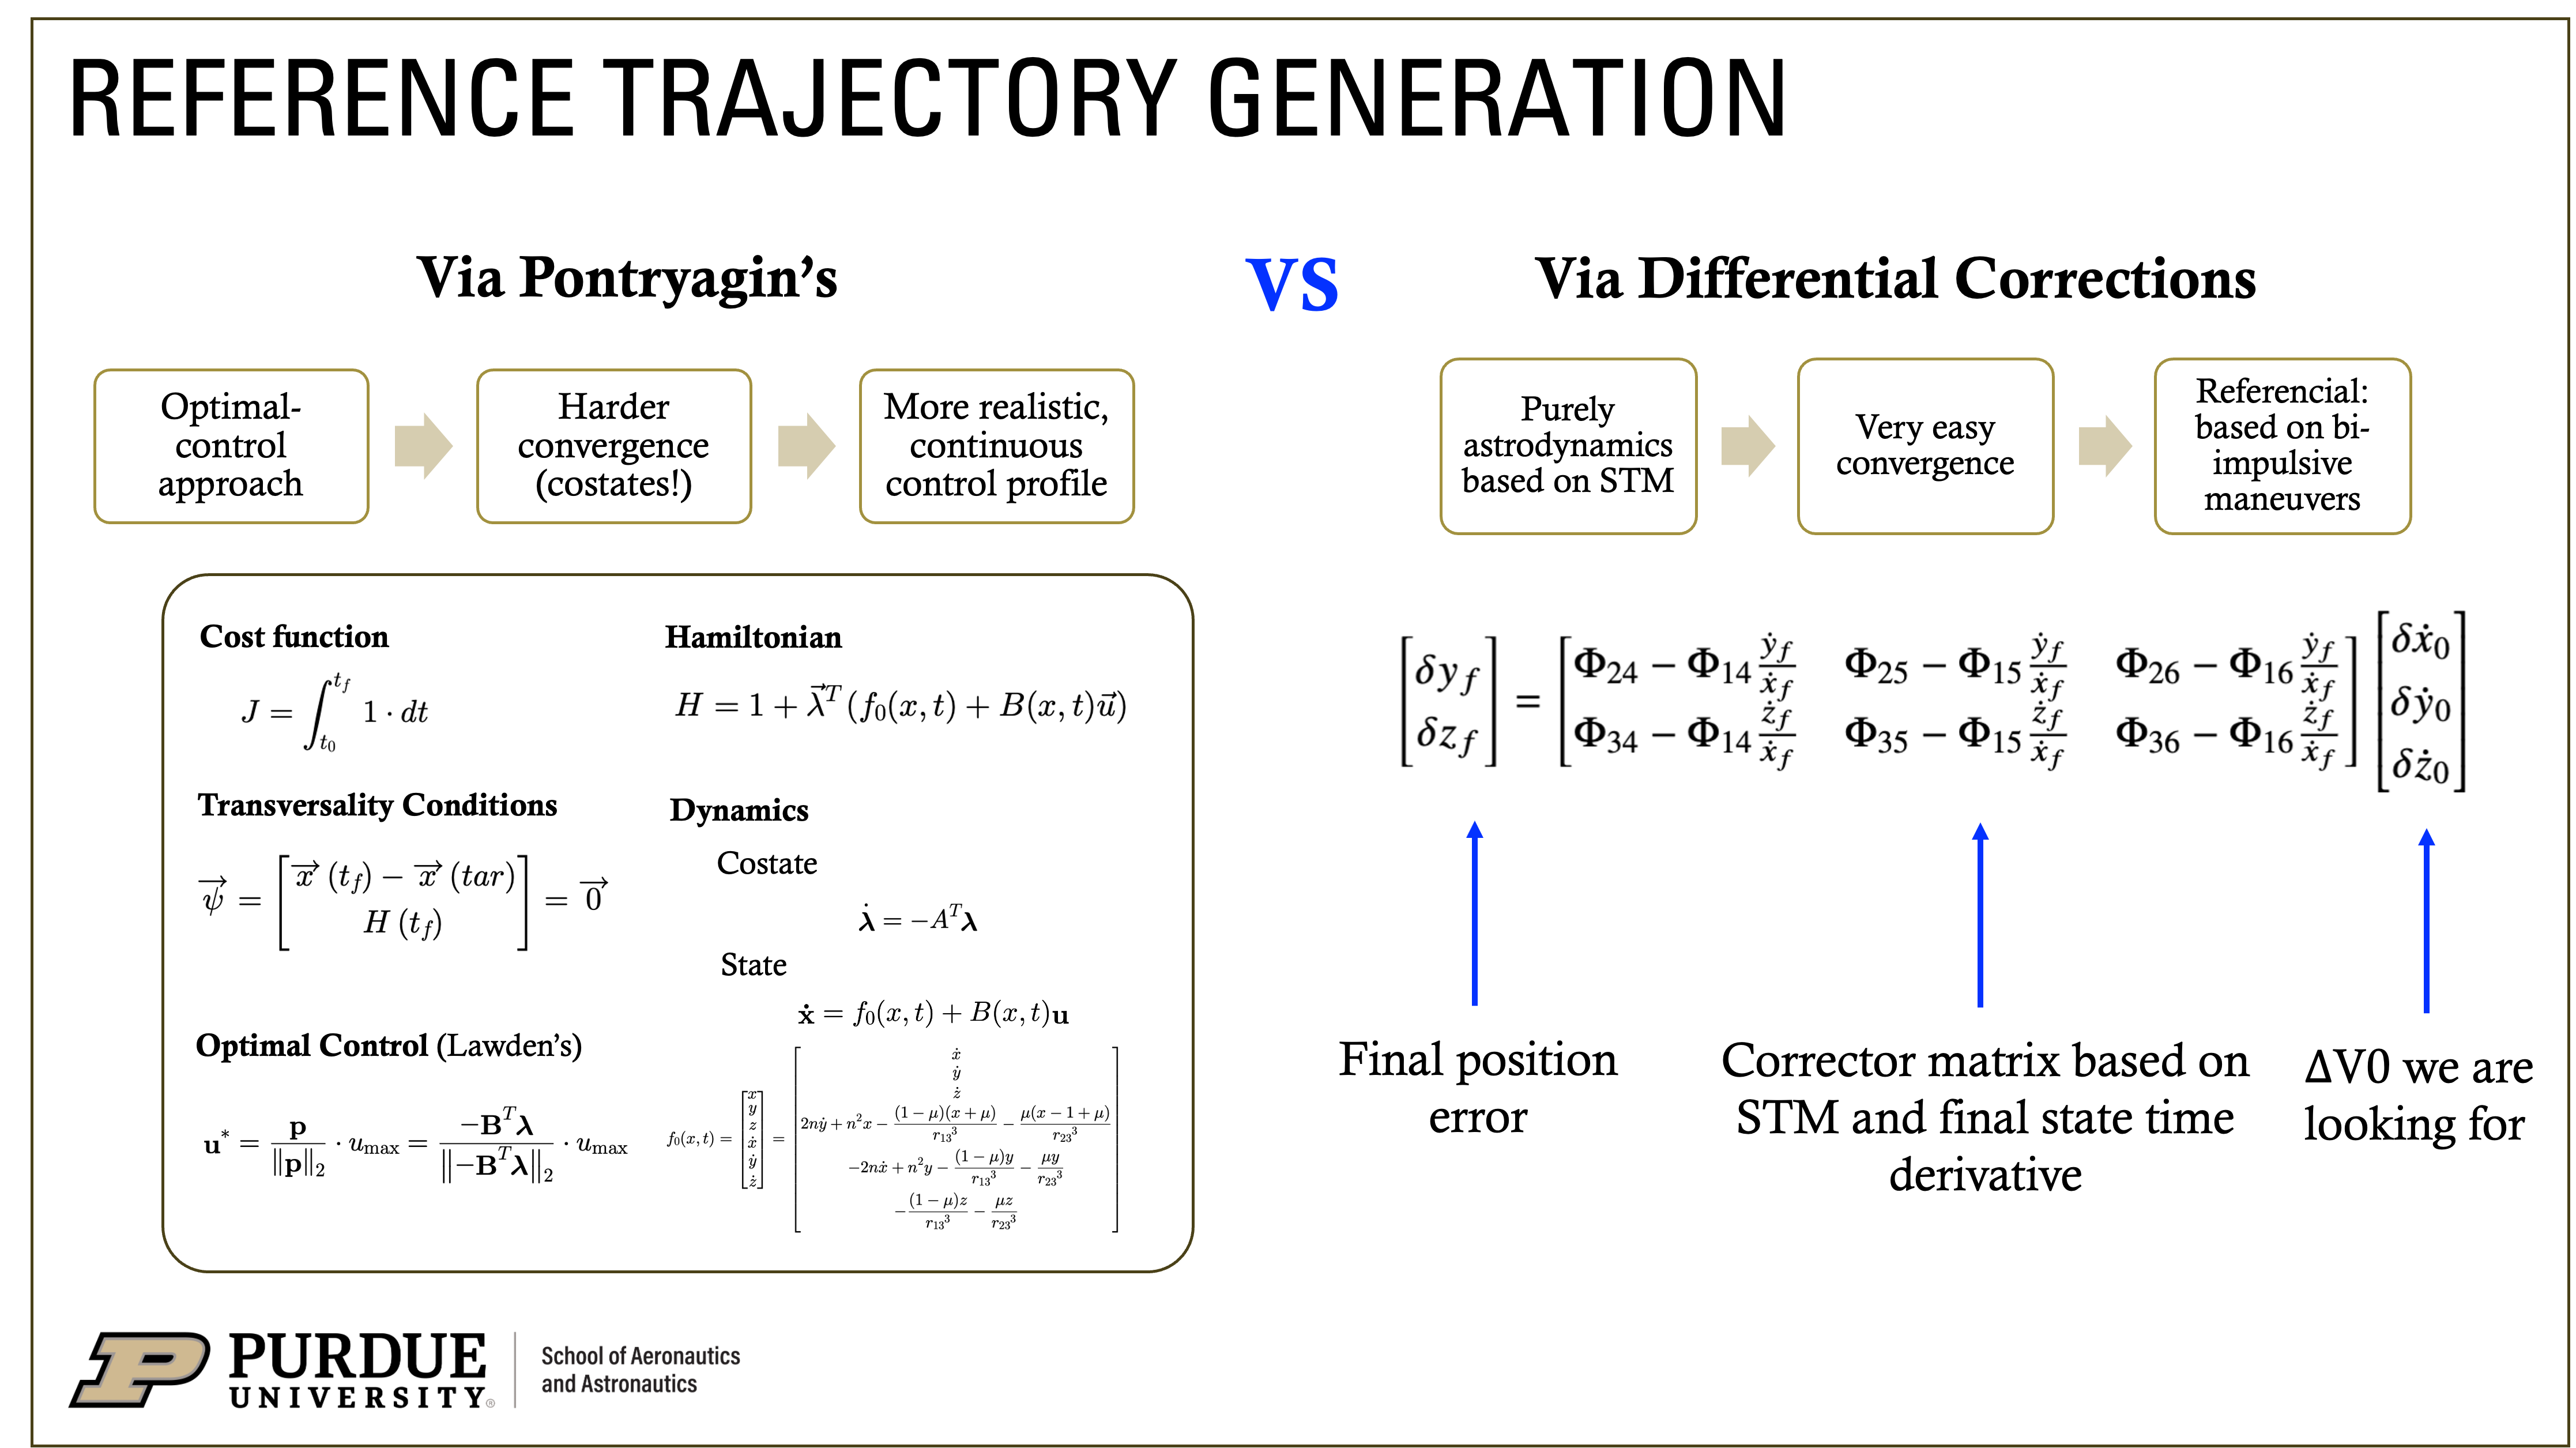
Distributed Consensus and Control for Multi-Satellite Debris Rendezvous
Distributed Consensus and Control for Multi-Satellite Debris Rendezvous
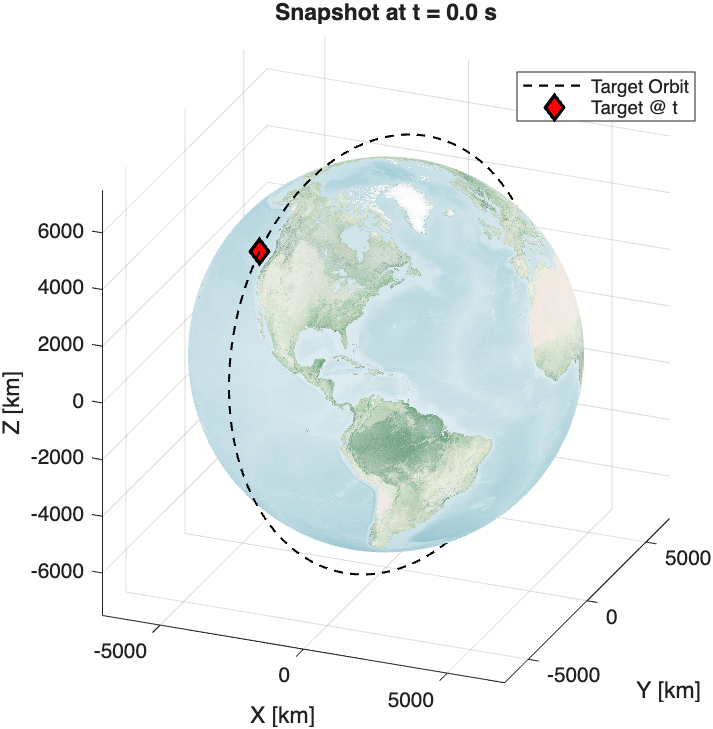
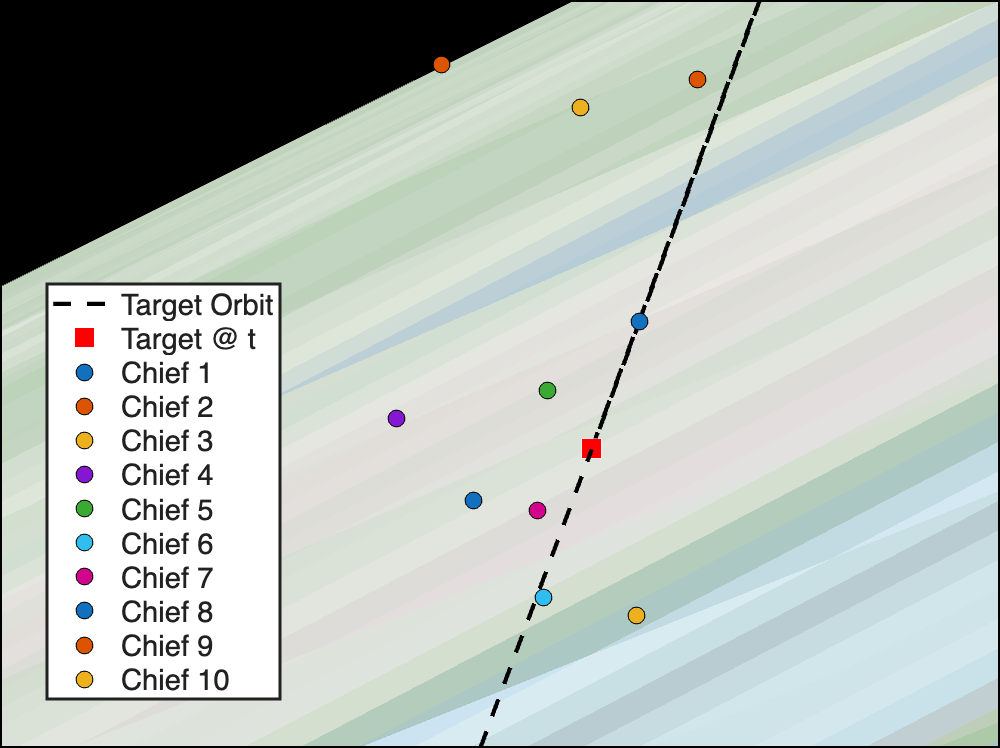
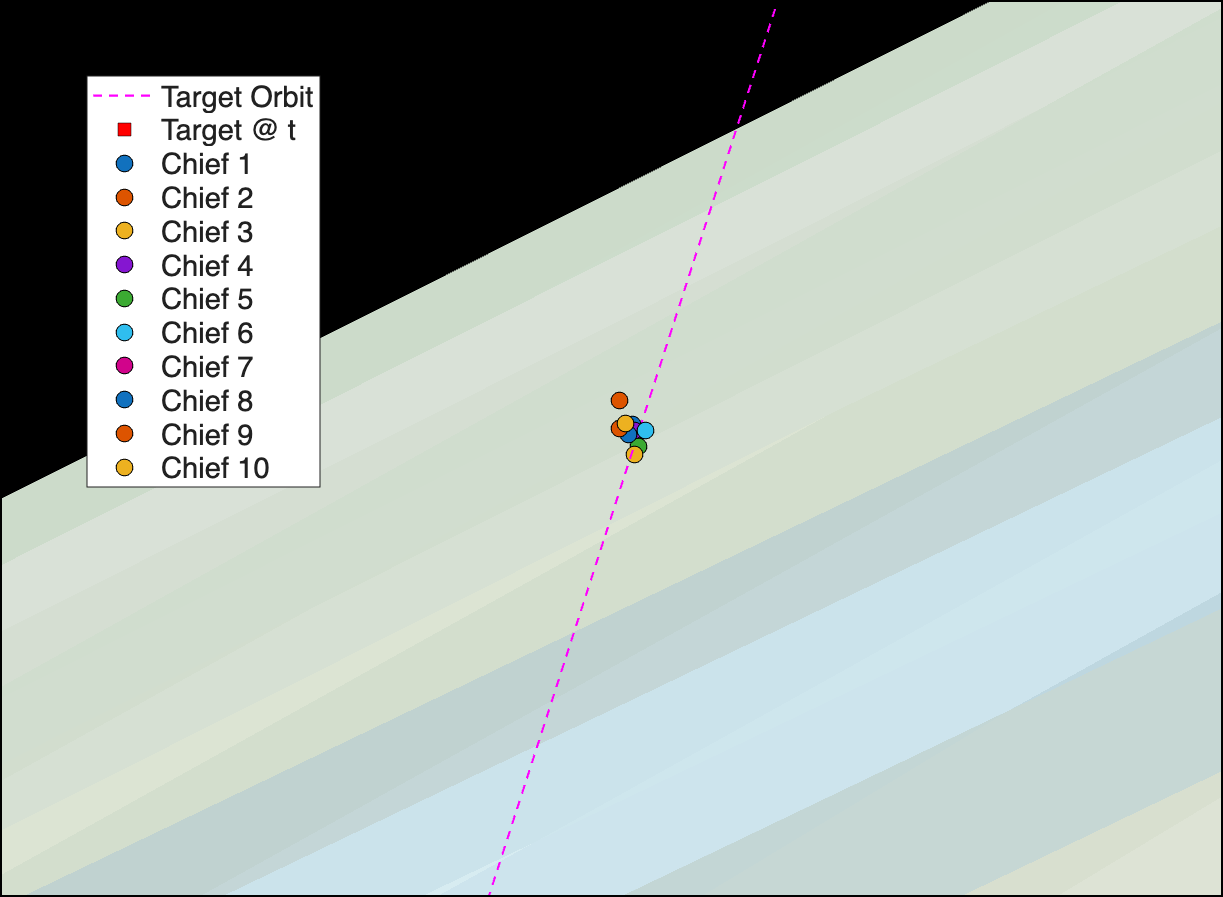
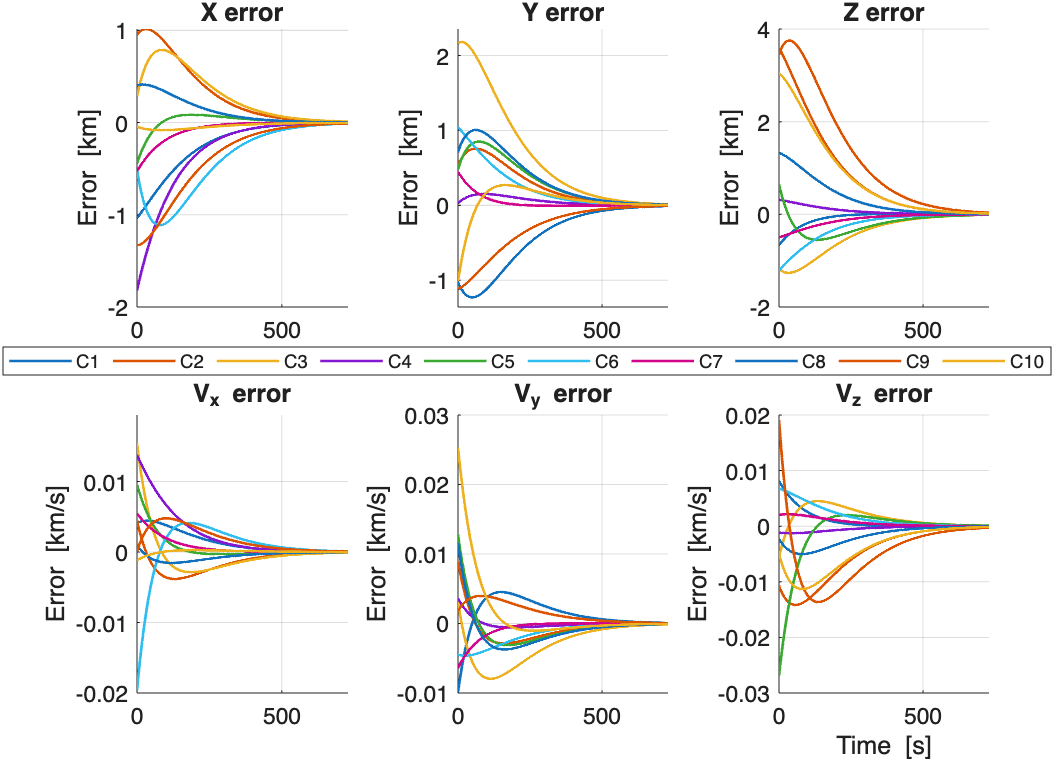
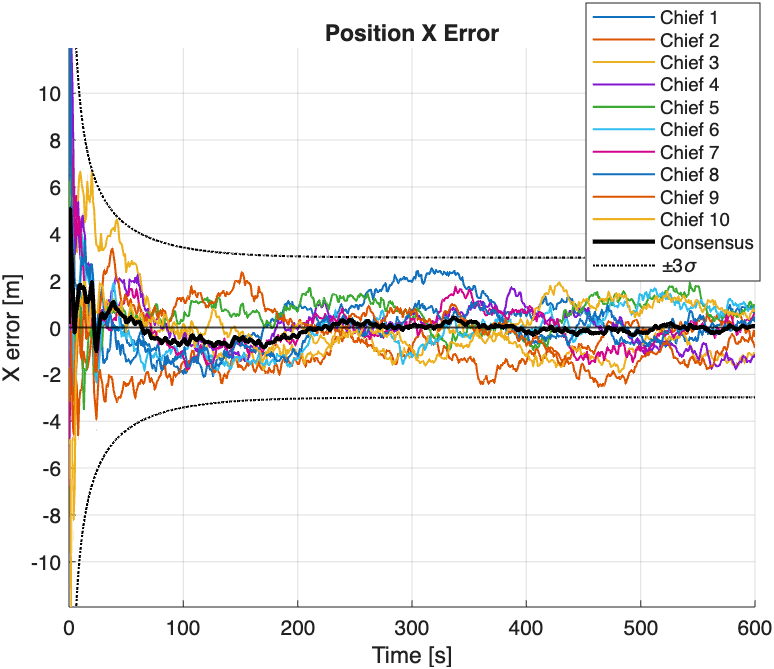
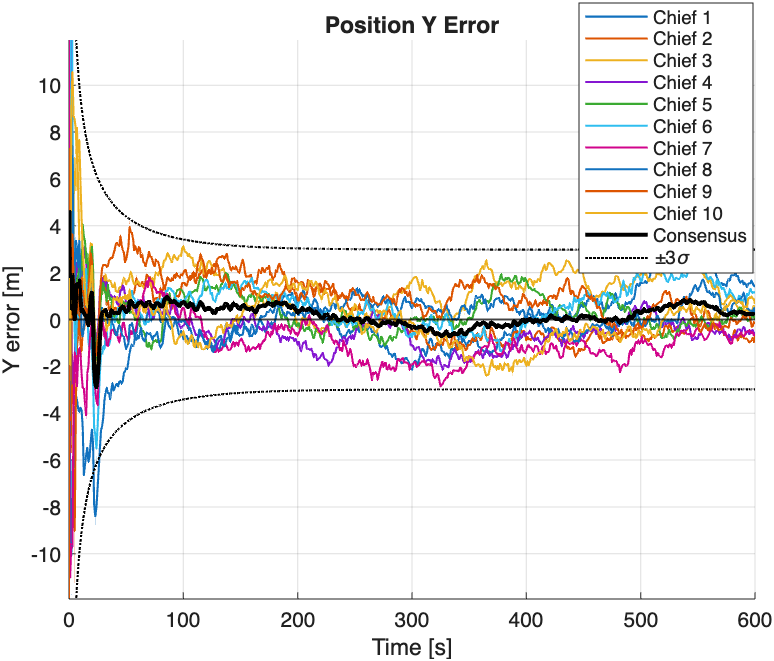
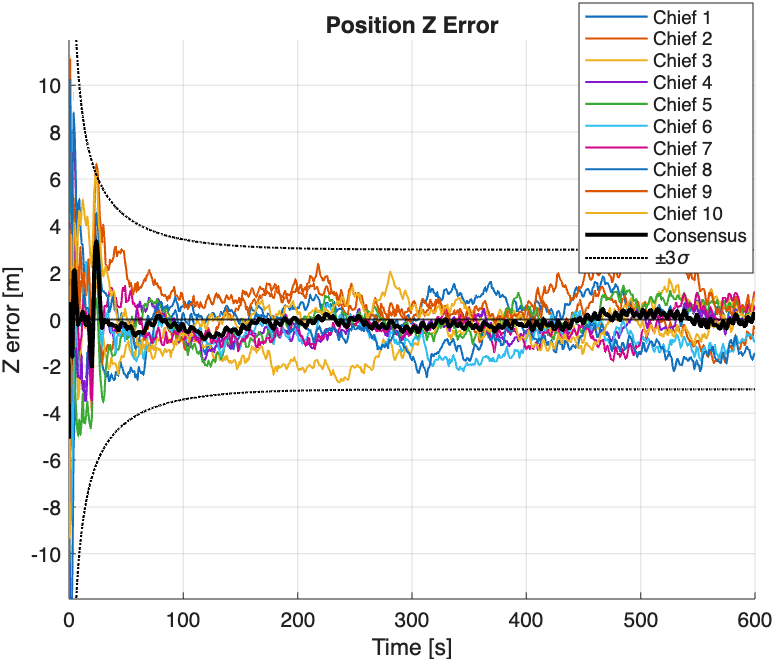
Designed a distributed estimation-and-control framework for cooperative rendezvous with large debris under J2-perturbed dynamics.
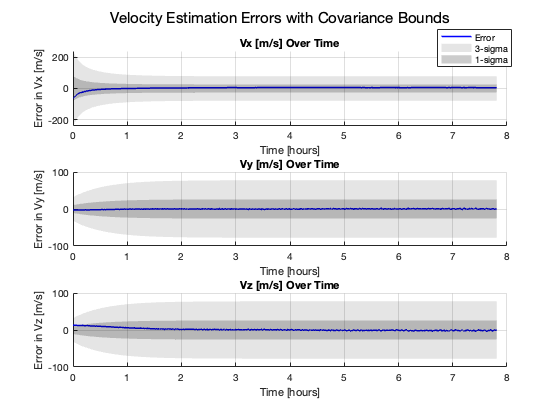
- Developed distributed EKF with Metropolis consensus for a 10-spacecraft Envisat case study.
- Achieved network-wide convergence in 11 iterations with 0.33 m position and 0.006 m/s velocity mean errors.
- Implemented PD guidance enabling meter-level rendezvous in 600 s with ΔV below 50 m/s per agent.
Completed as part of AAE590 MAAC (2024) at Purdue University.
 2024
Model Predictive Control for Direct Moon Landing from LPO
Model Predictive Control for Direct Moon Landing from LPO
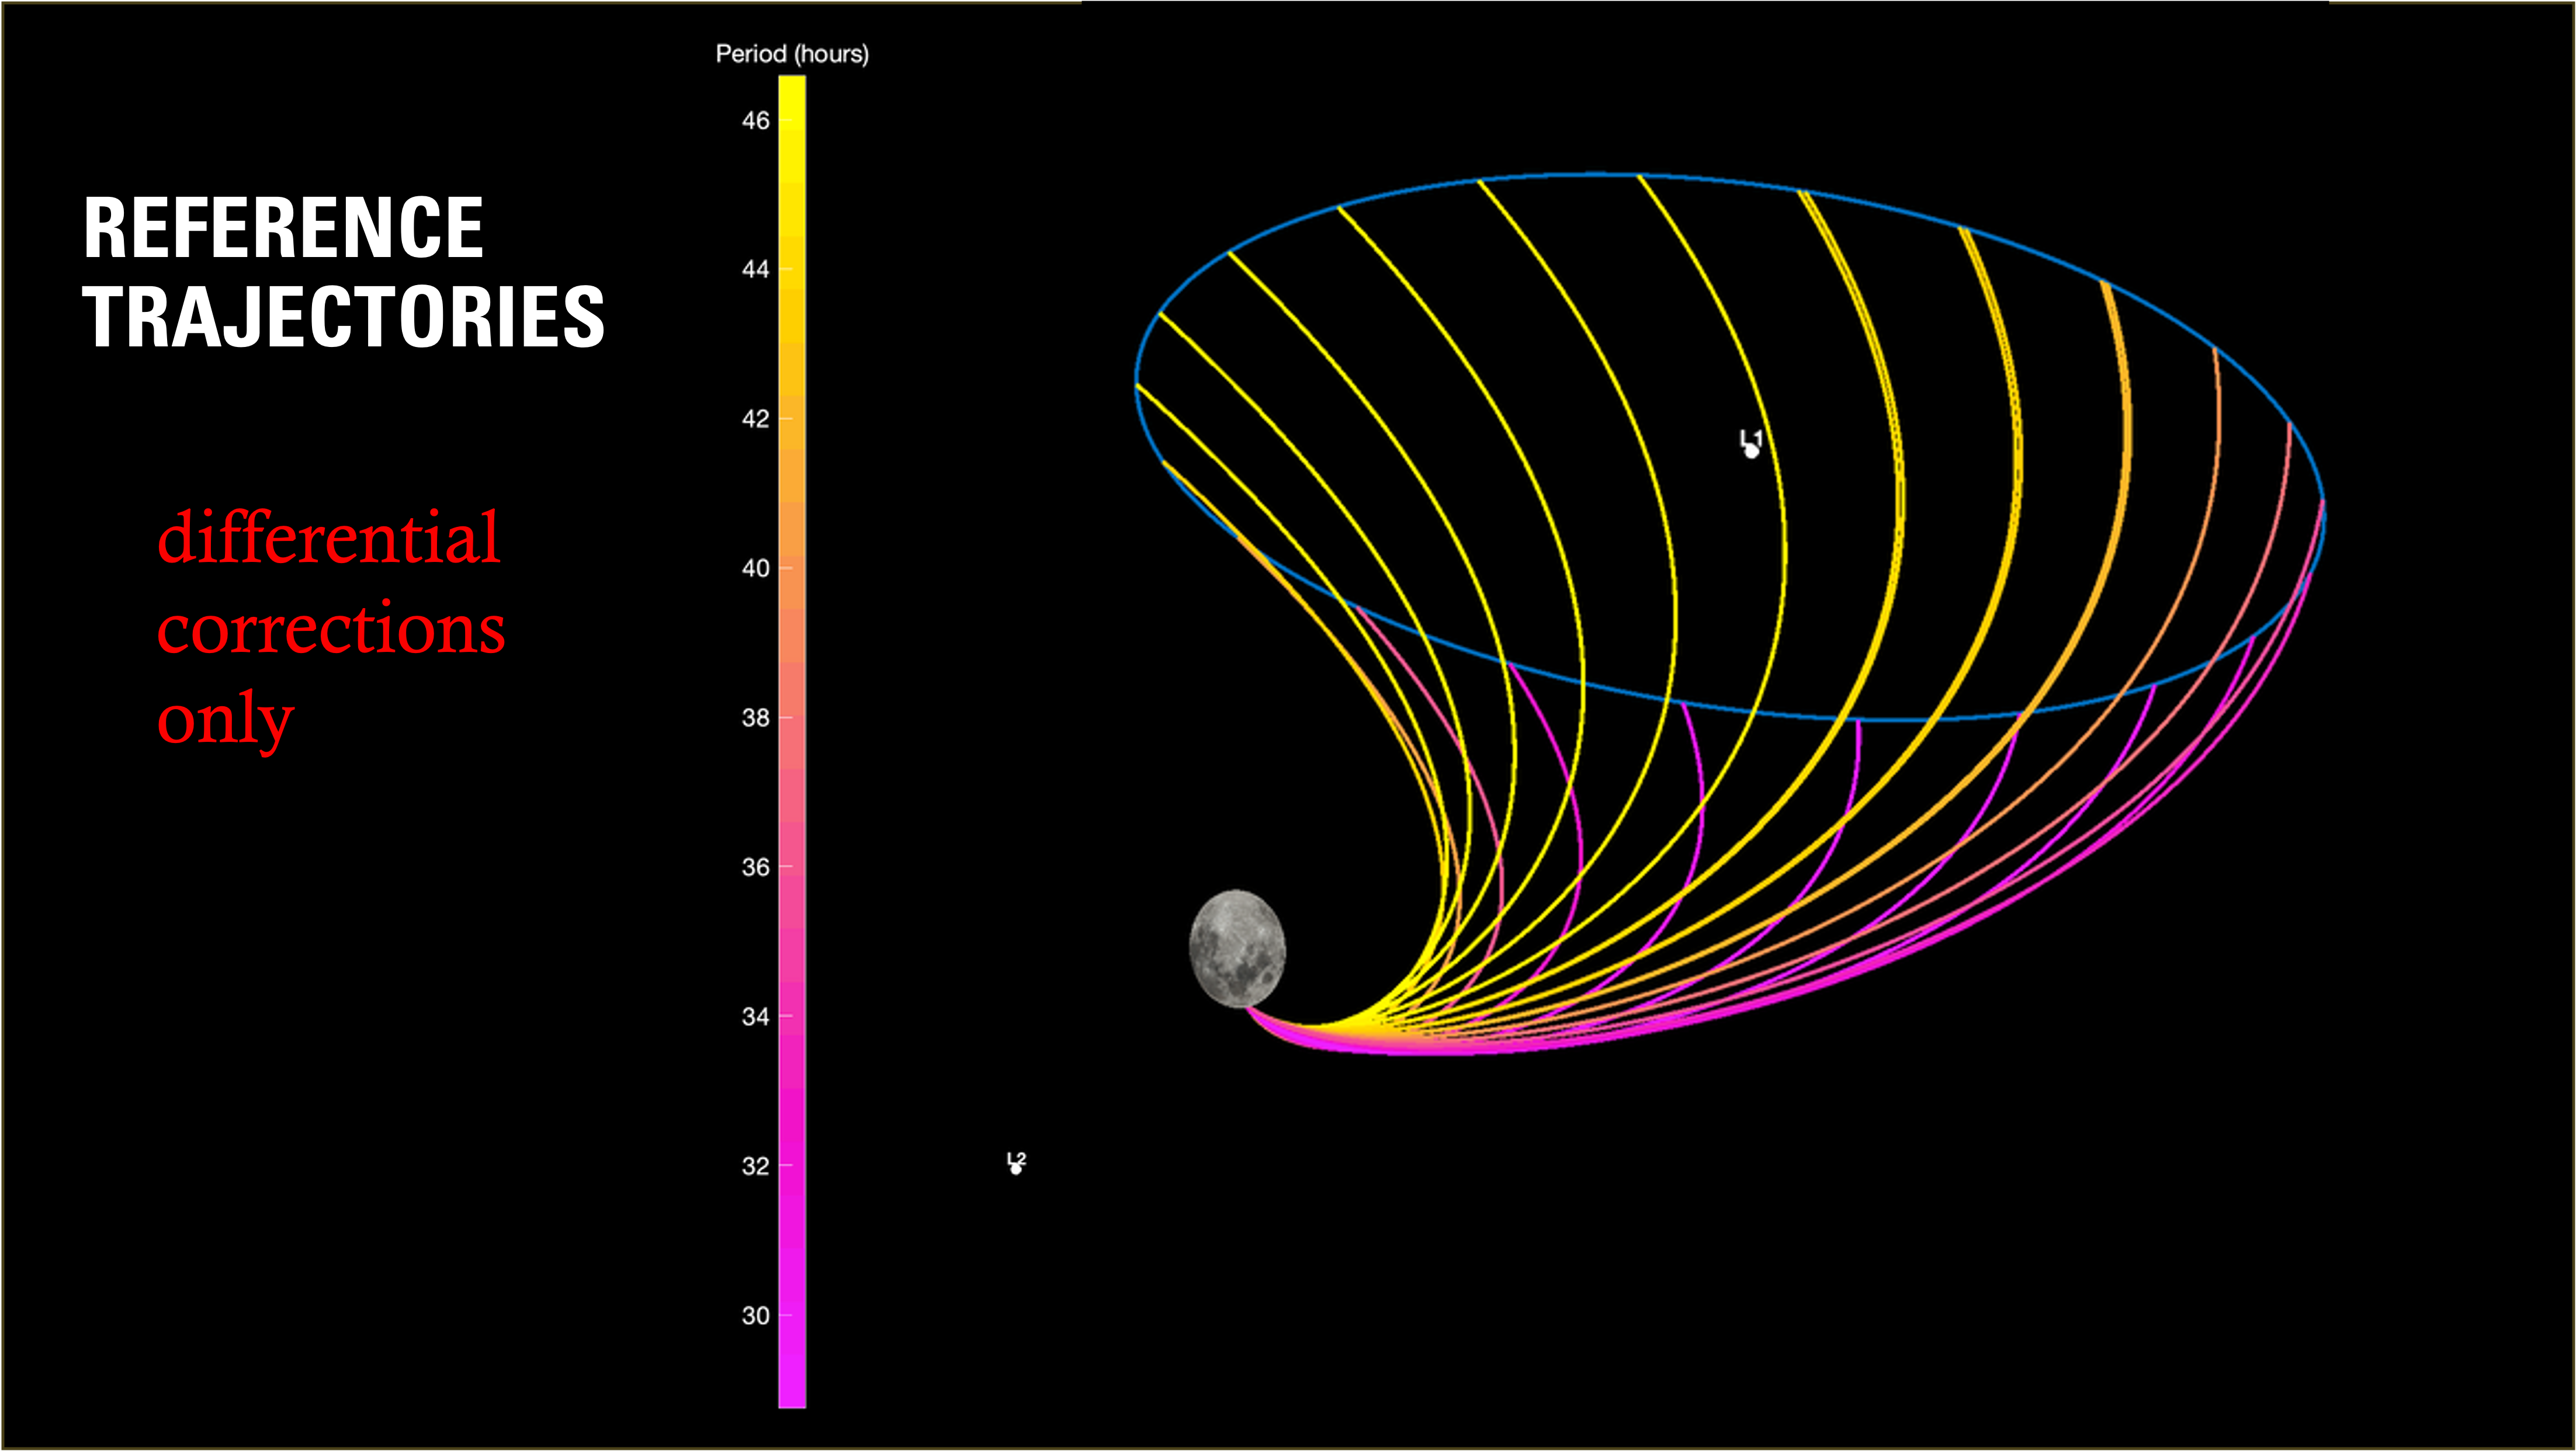
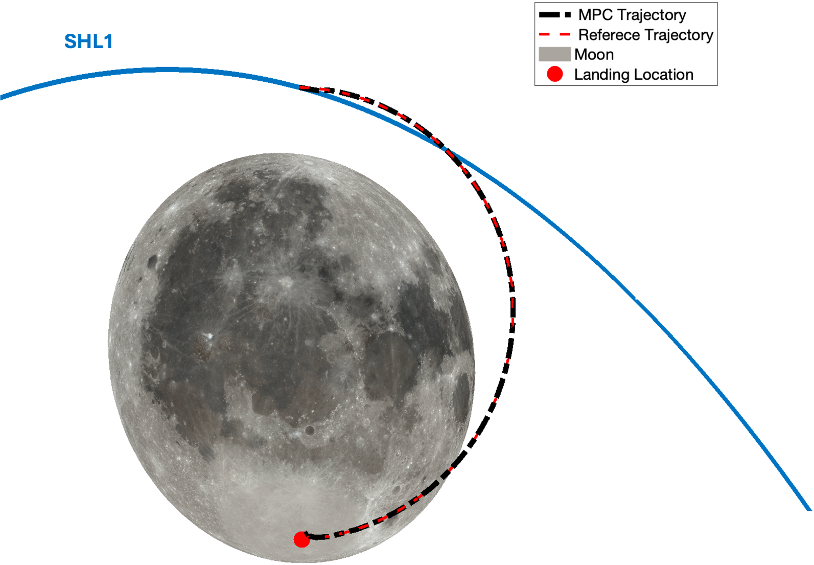
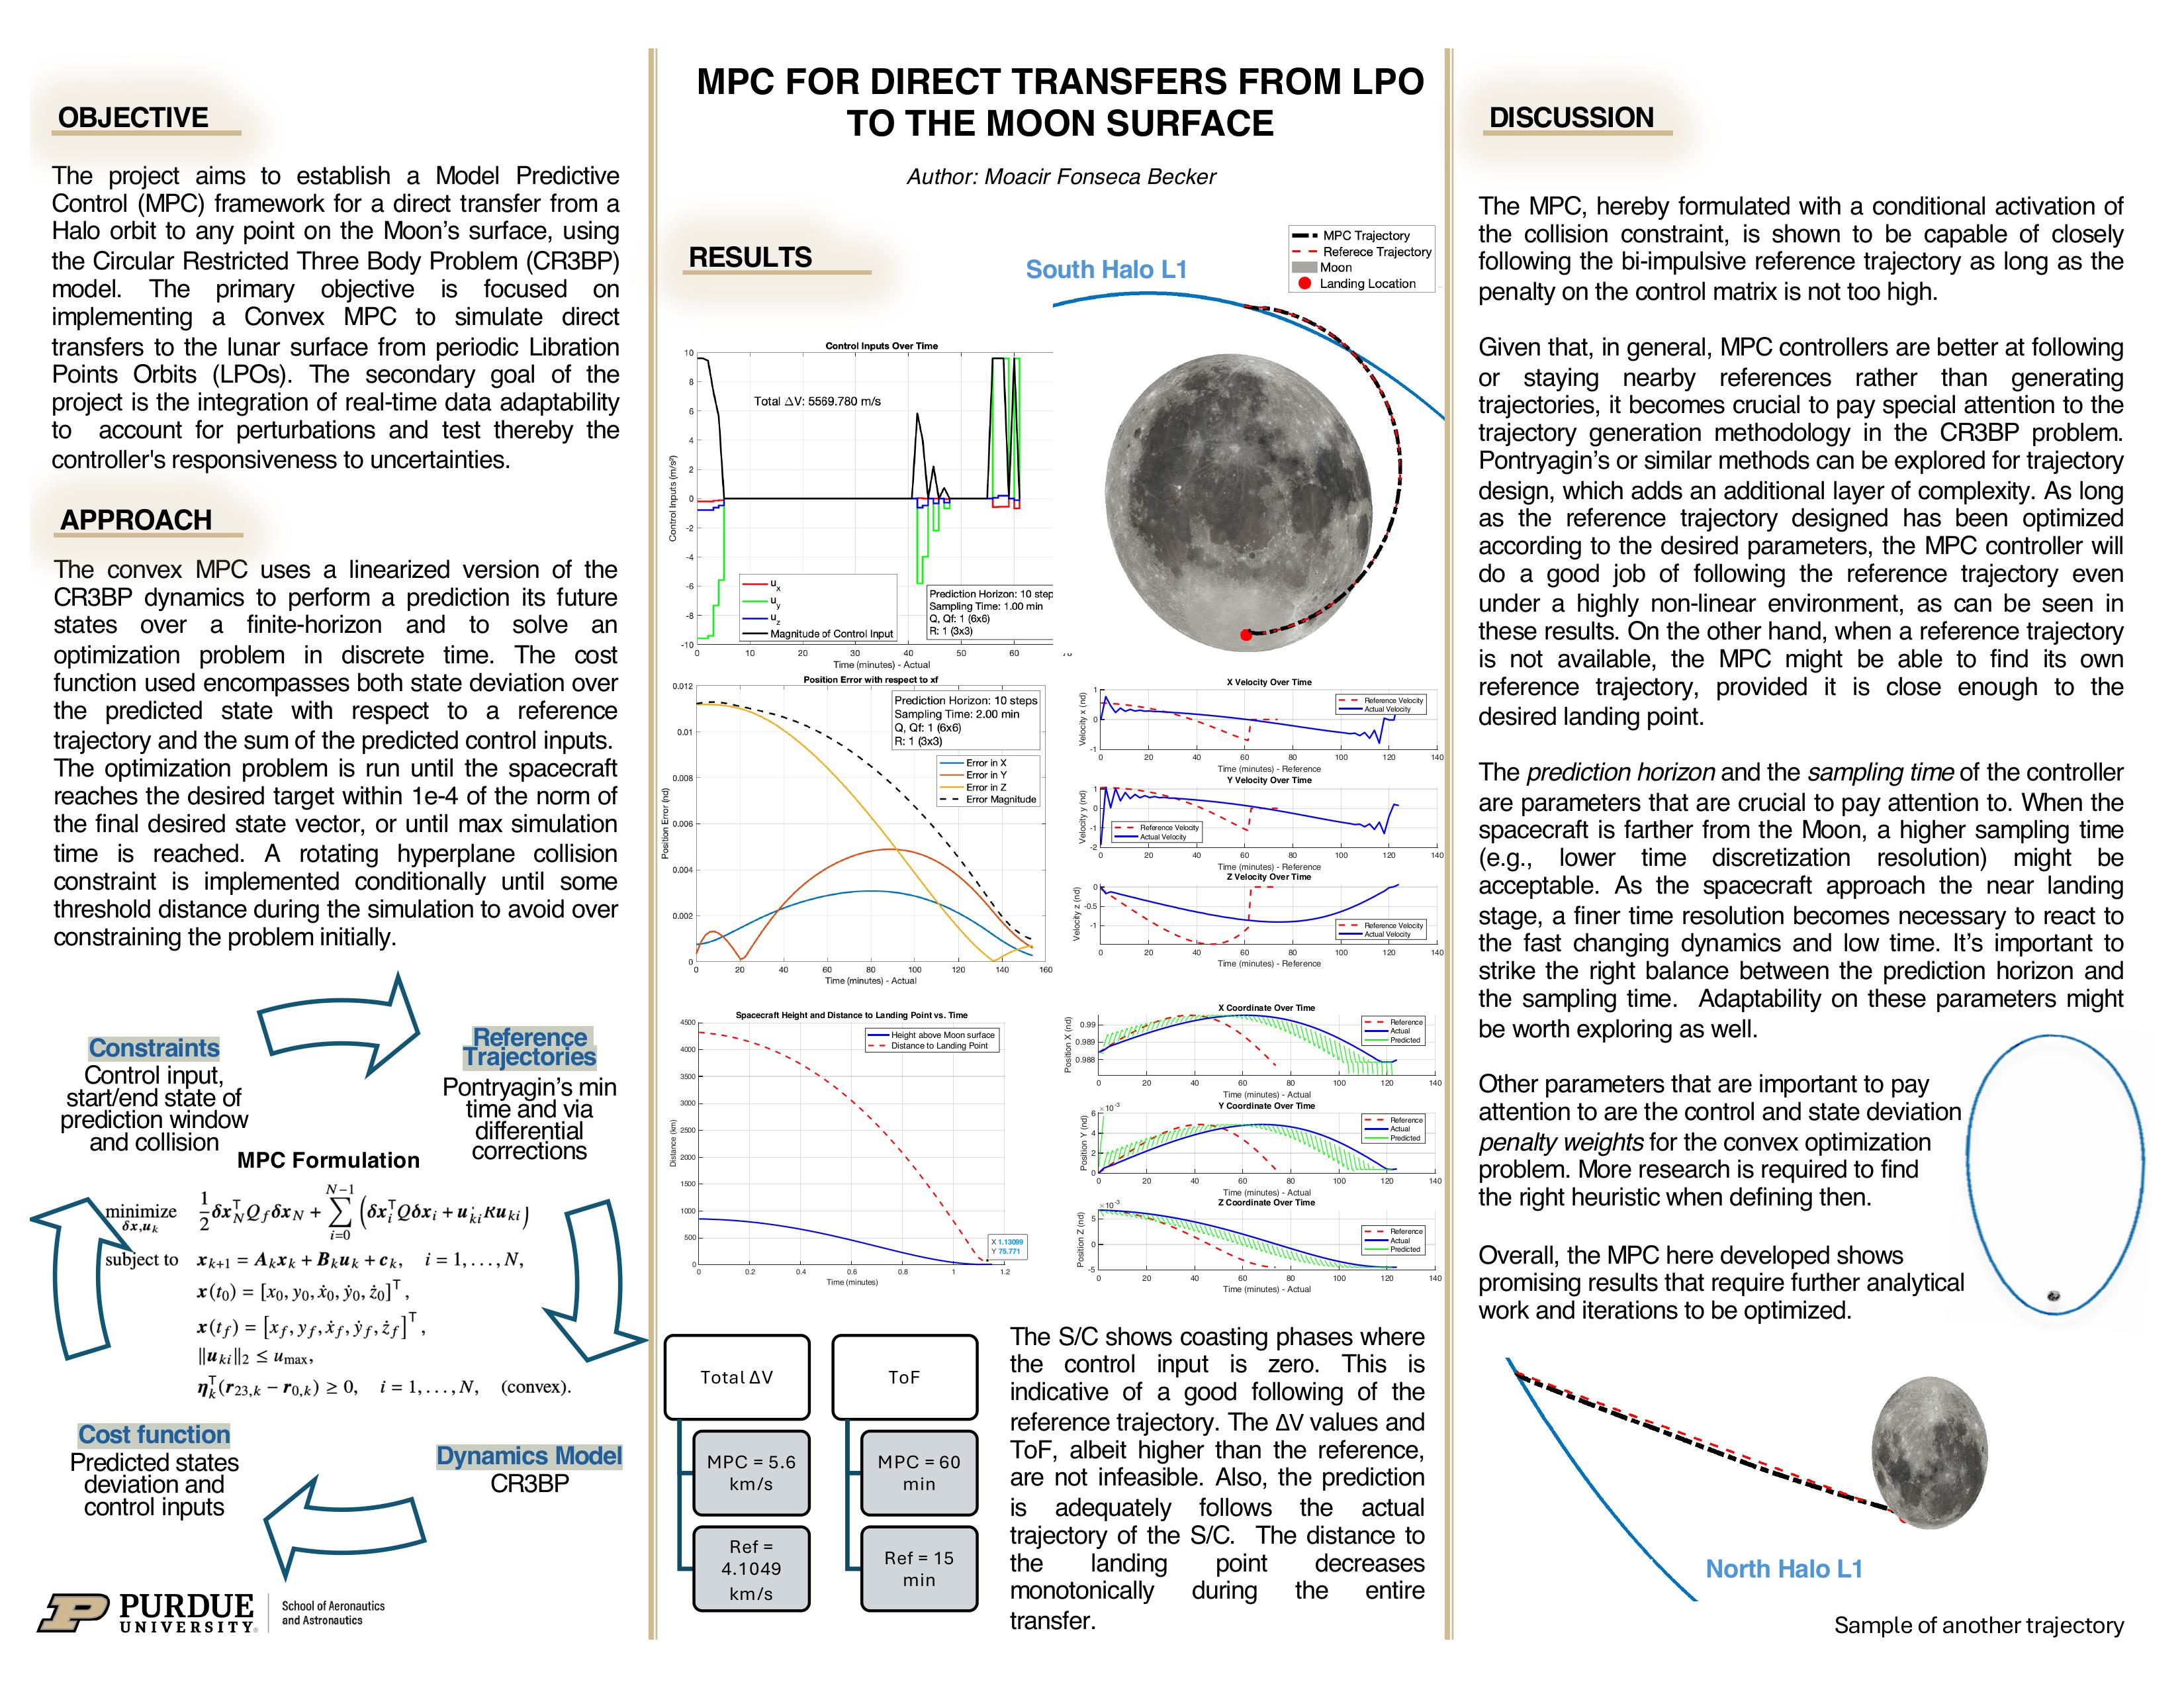
Developed a convex MPC framework for direct transfers from Libration Point Orbits to targeted lunar surface landing sites.
- Focused on precision landing scenarios near the lunar south pole.
- Implemented conditional collision constraints within a linearized CR3BP dynamics model.
- Demonstrated trajectory tracking and perturbation adaptation using state and control penalty tuning.
Completed as part of AAE590 Advanced Control Applications (2024) at Purdue University.
 2023
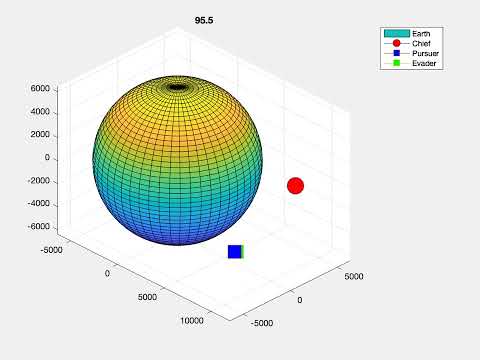
Orbital pursuer evasion game with incomplete information - class project
Orbital pursuer evasion game with incomplete information - class project
This project tackles orbital pursuit-evasion, where a spacecraft must capture a moving target in orbit while dealing with incomplete information.
- Used Unscented Kalman Filter estimation for evader state and strategy inference.
- Compared complete-information, zero-sum, and UKF-informed control approaches.
- Modeled dynamics with Euler-Hill equations for realistic debris-like scenarios.
Completed as part of Optimal Control and Estimation (AAE5980) at Purdue University.
 2023
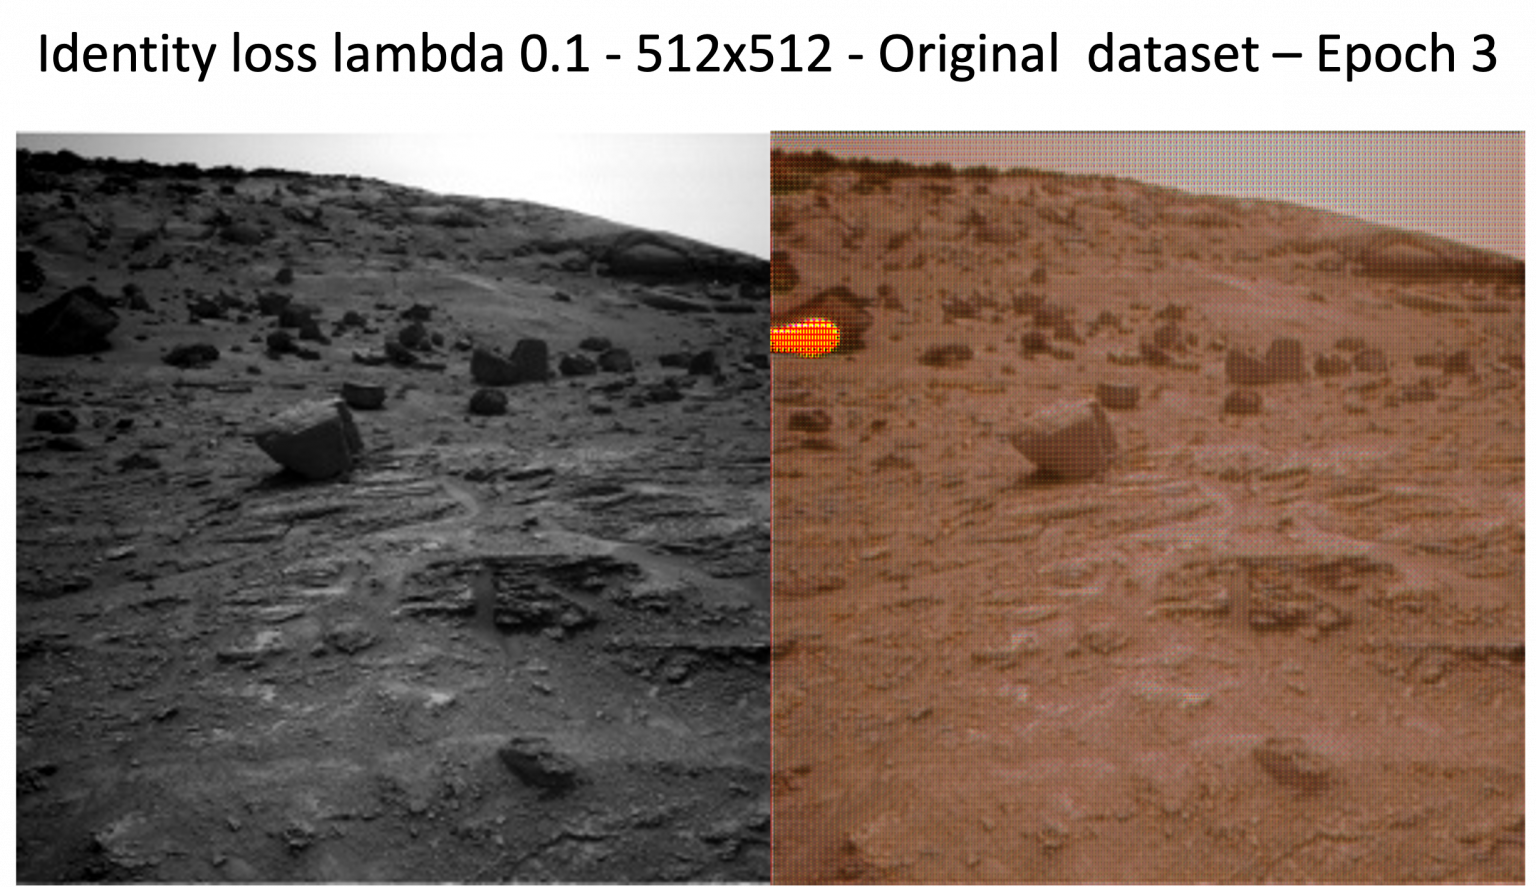
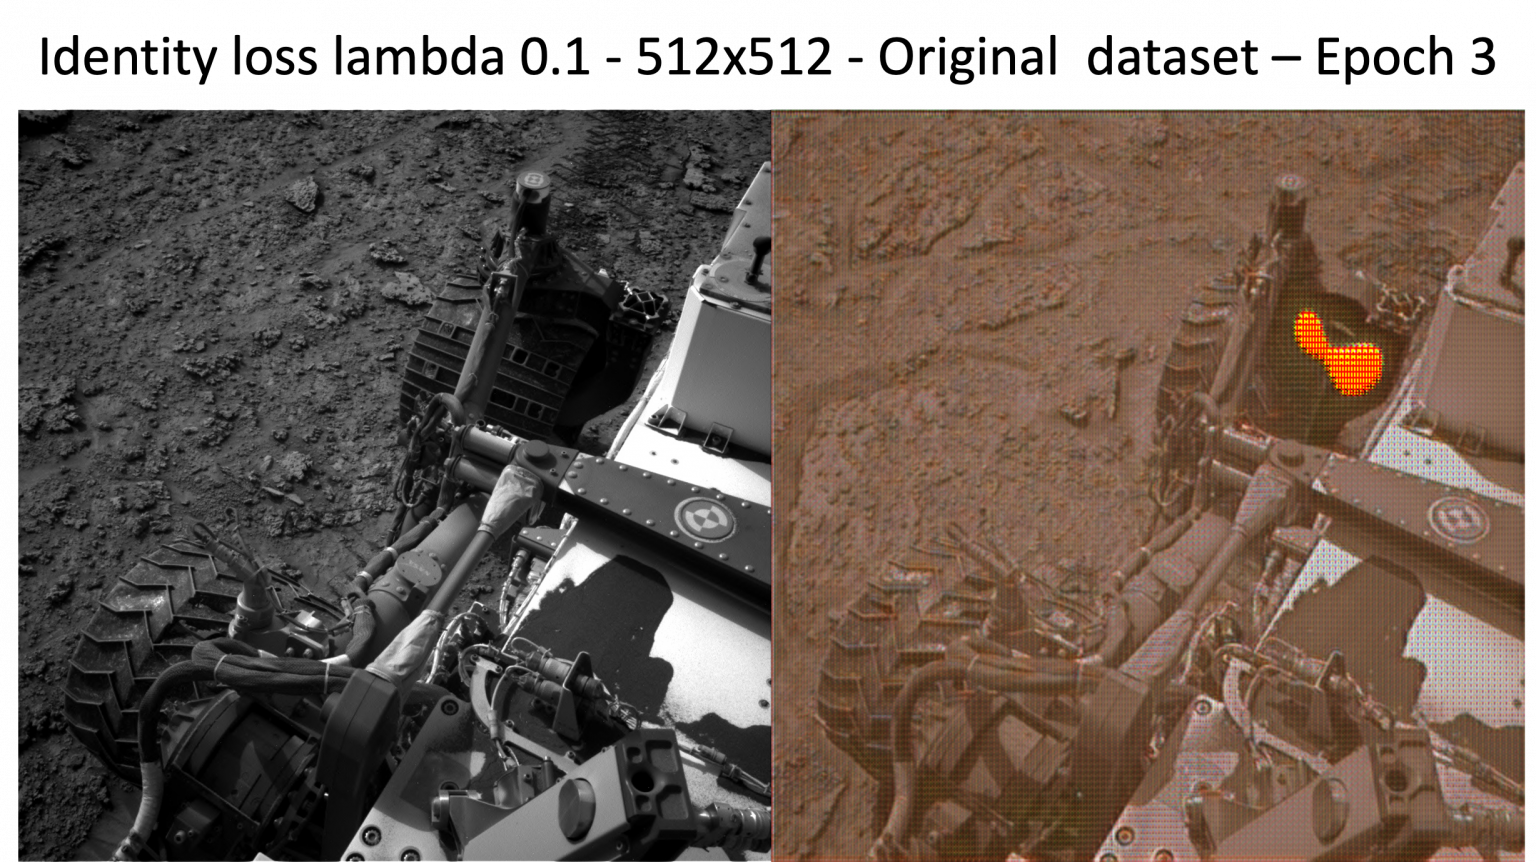
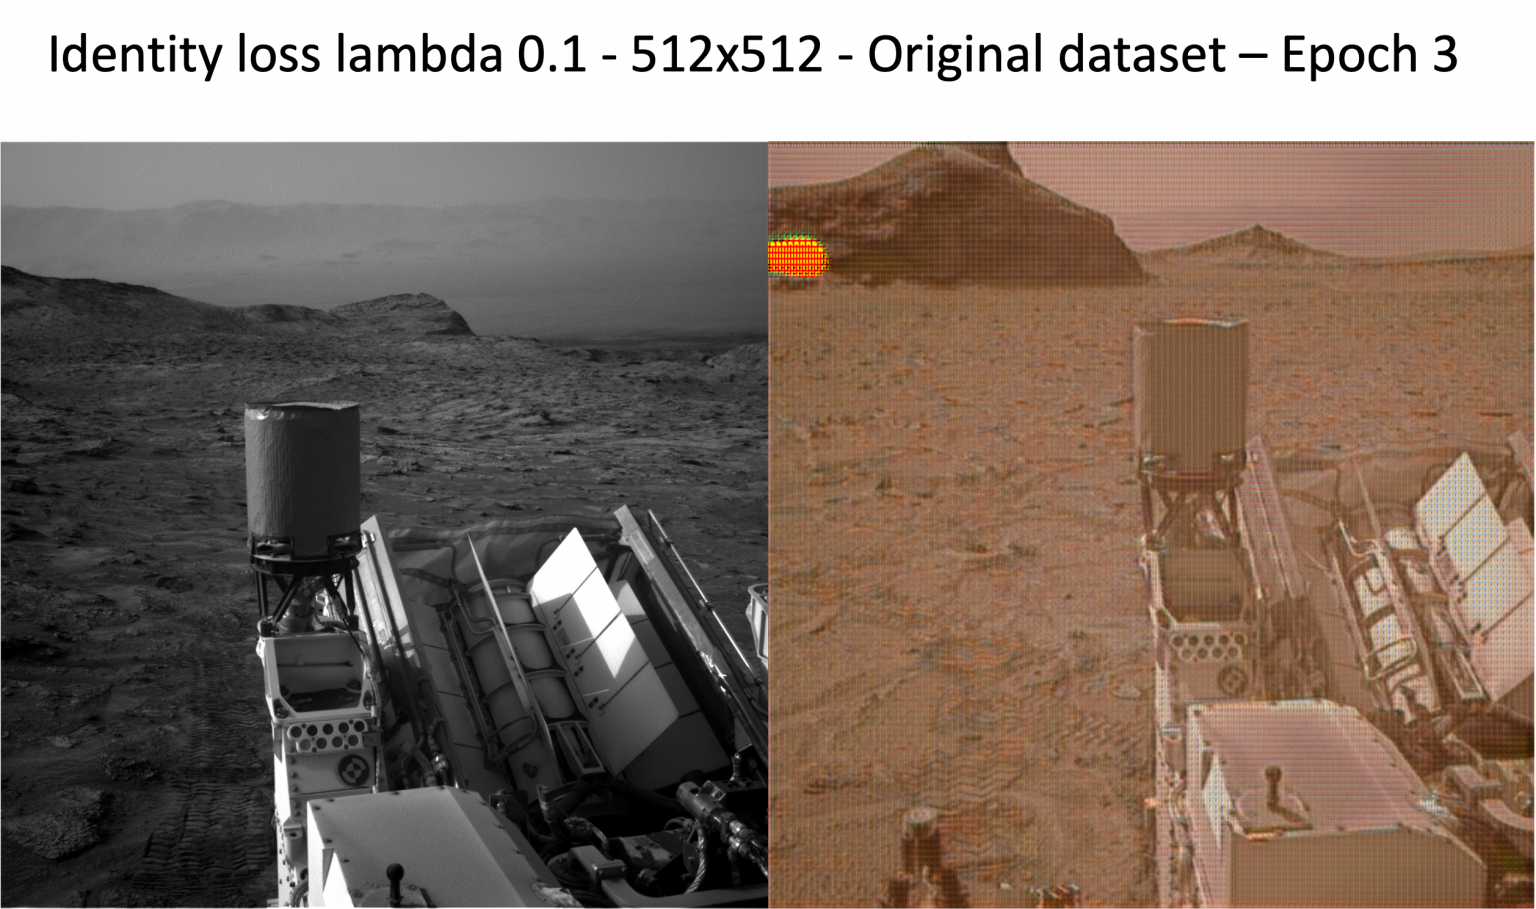
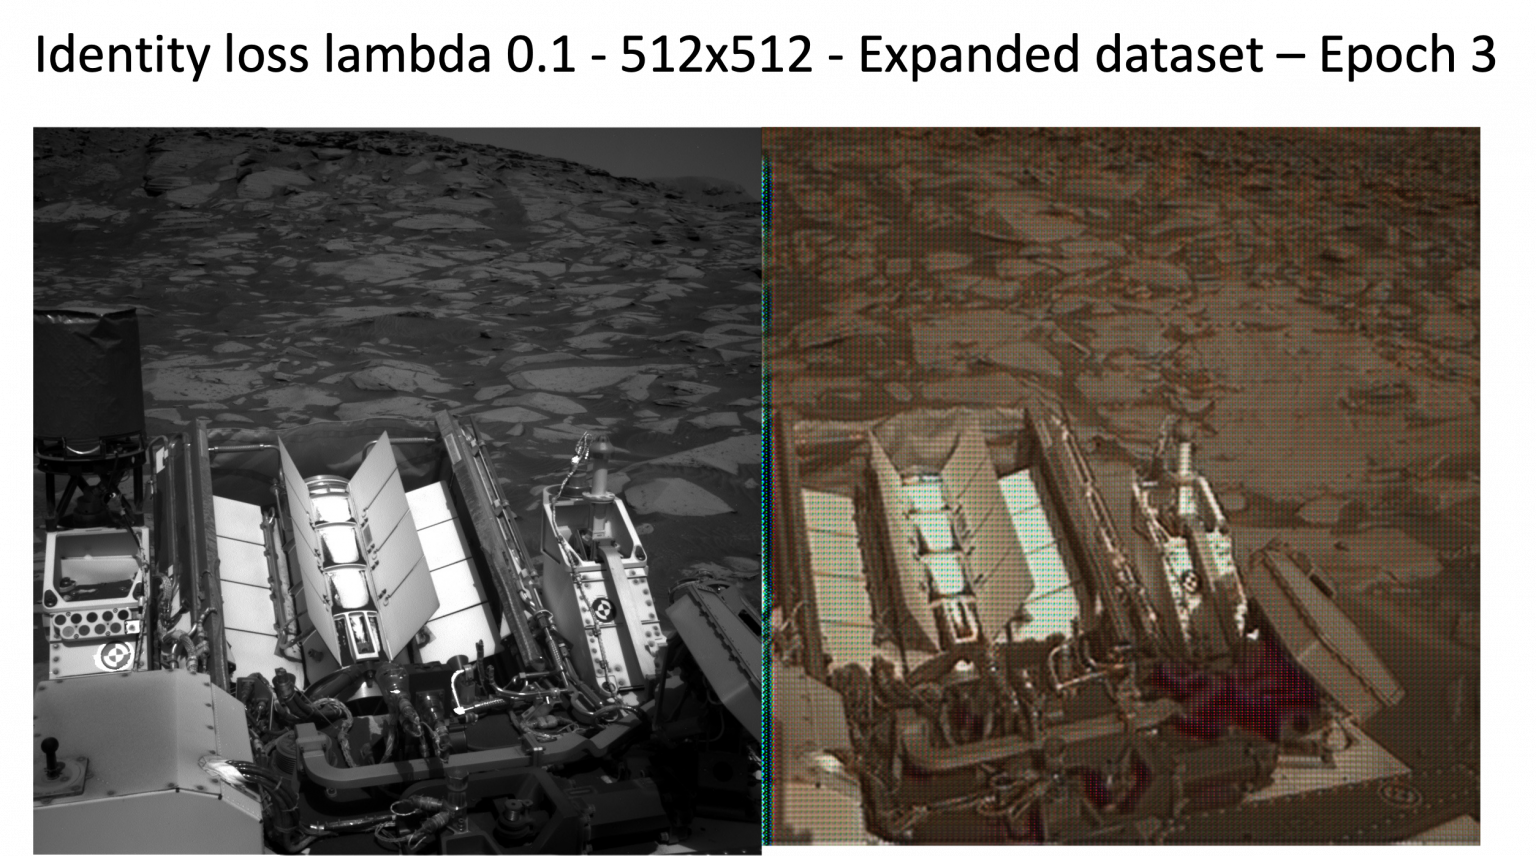
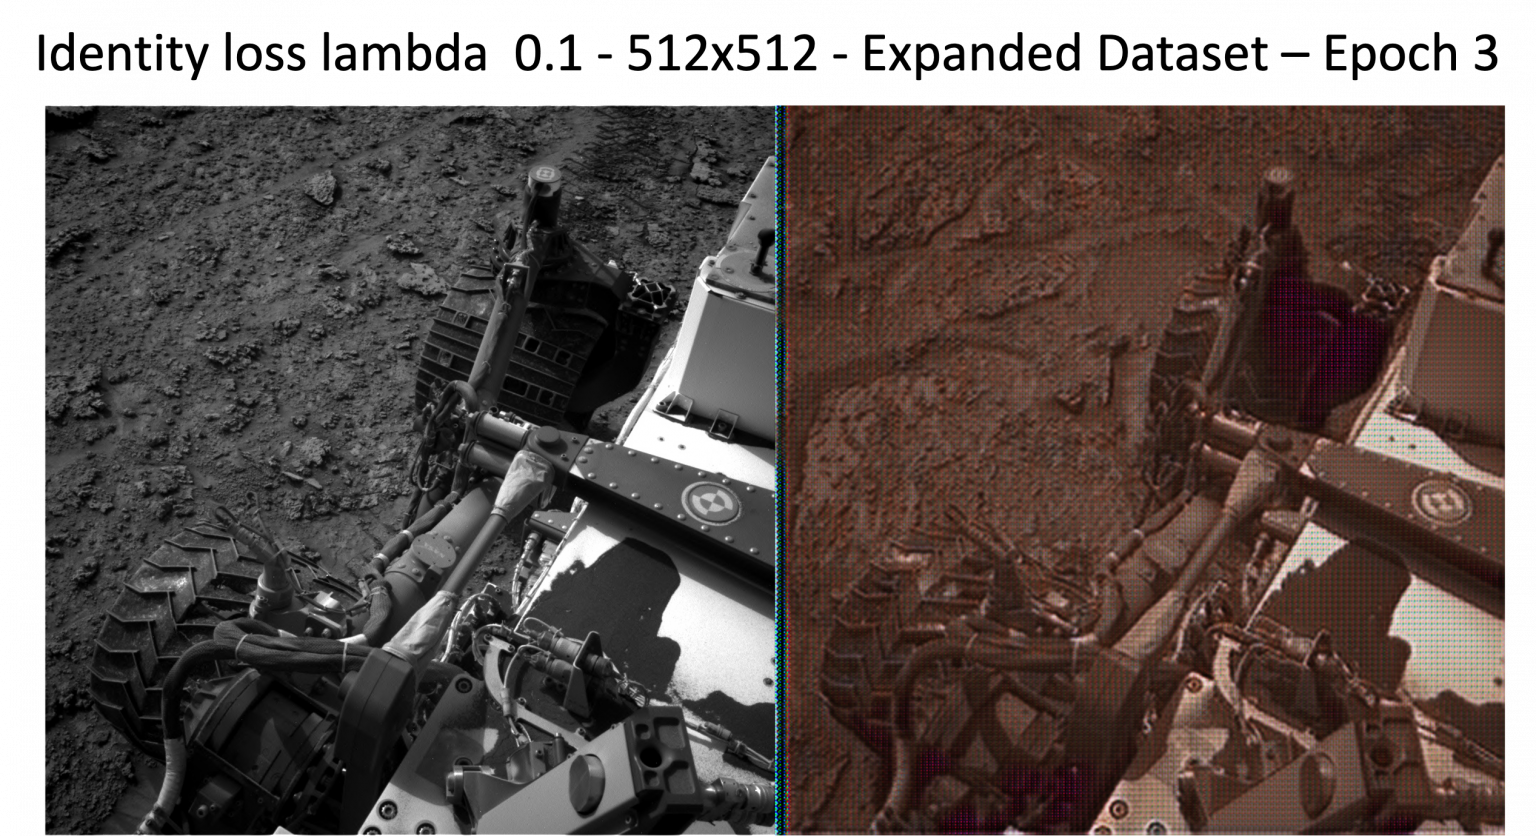
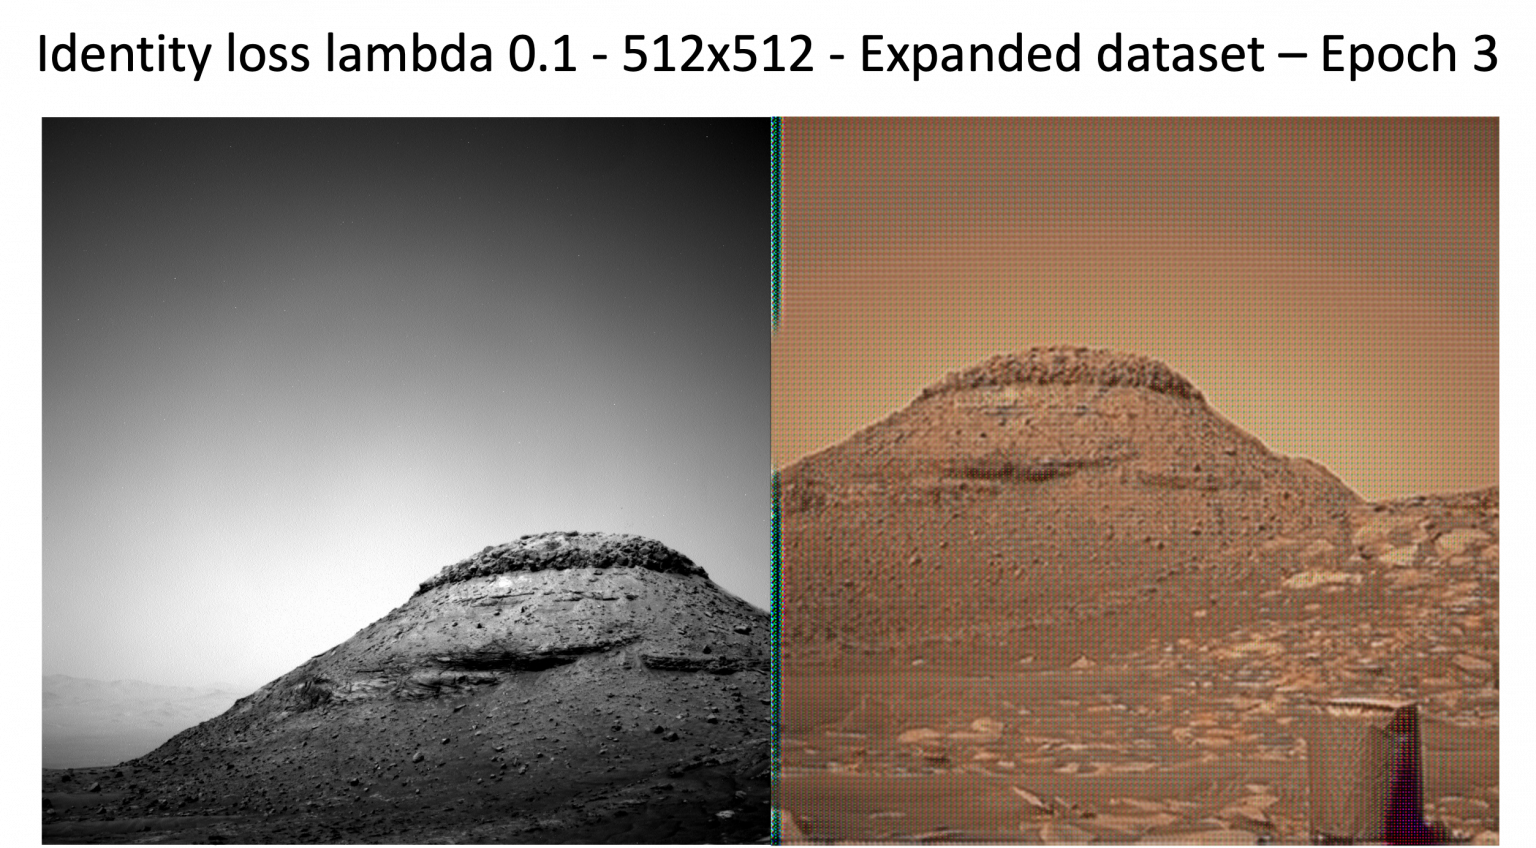
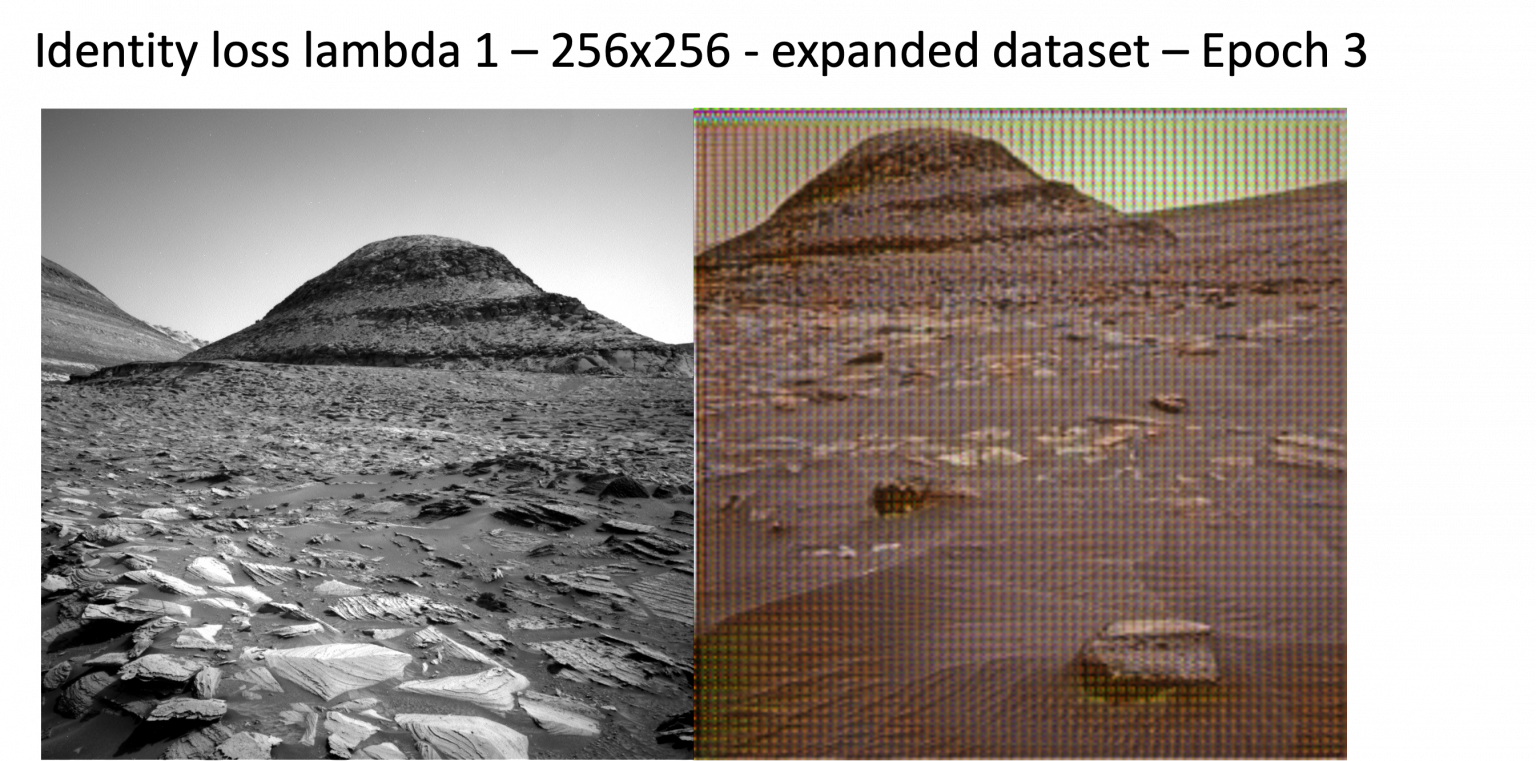
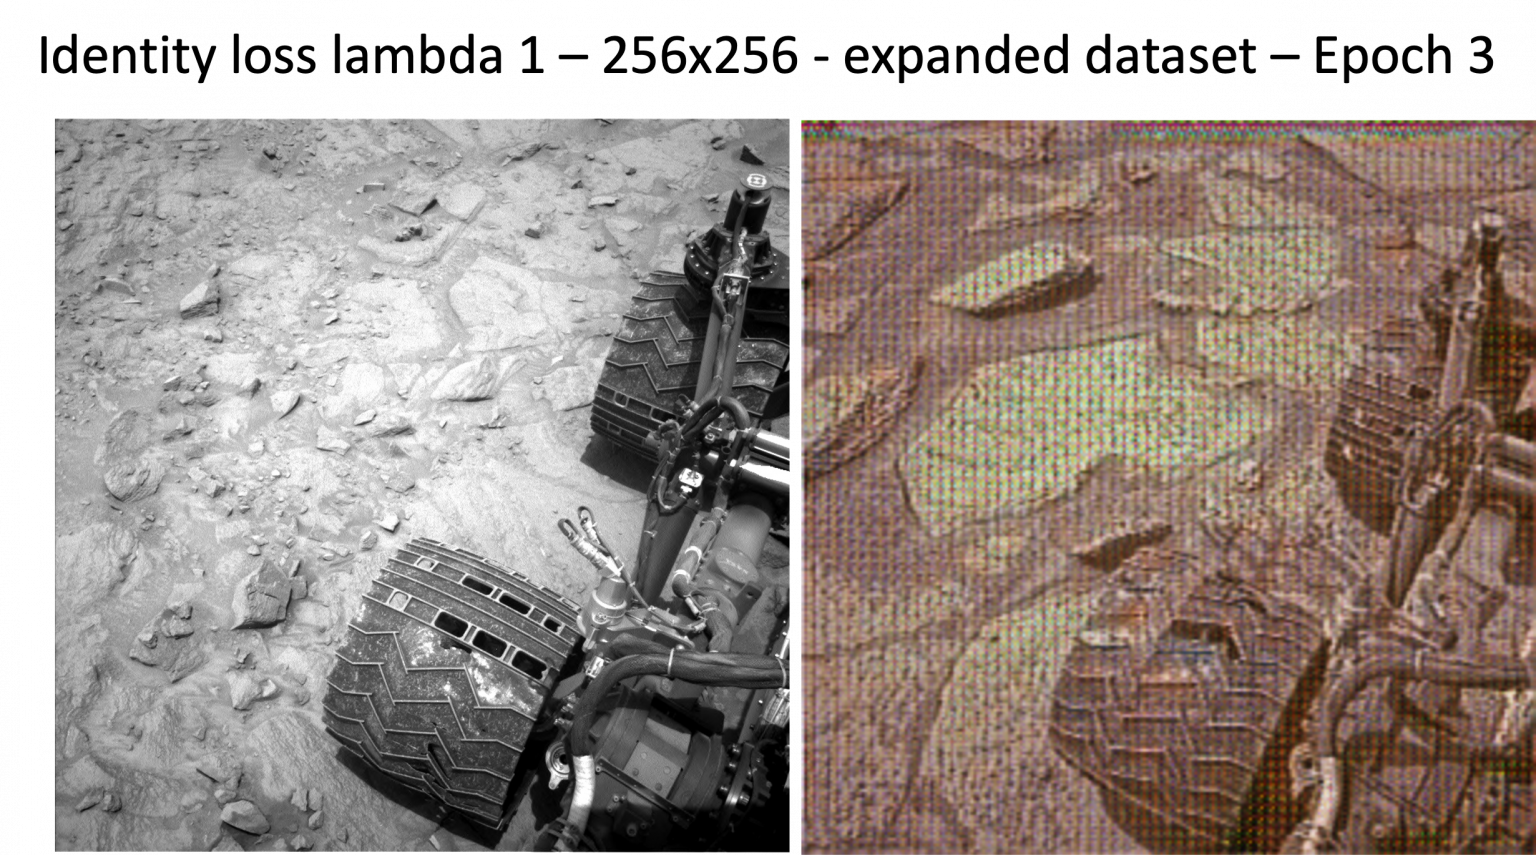
Using Cycle-Consistent Adversarial Networks translation to color surface images of Mars
Using Cycle-Consistent Adversarial Networks translation to color surface images of Mars
Machine learning project focused on translating Mars surface imagery into color representations using CycleGAN methods.
Completed as part of Machine Learning (STAT598 / ECE595) at Purdue University.
 2023
Distributed machine learning across AI companies - class project
Distributed machine learning across AI companies - class project
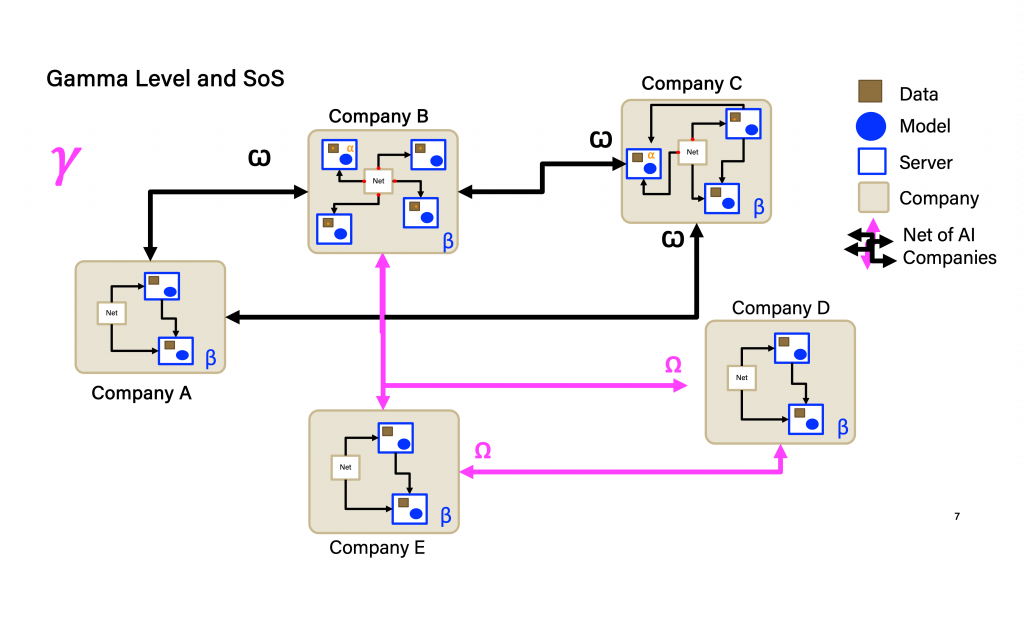
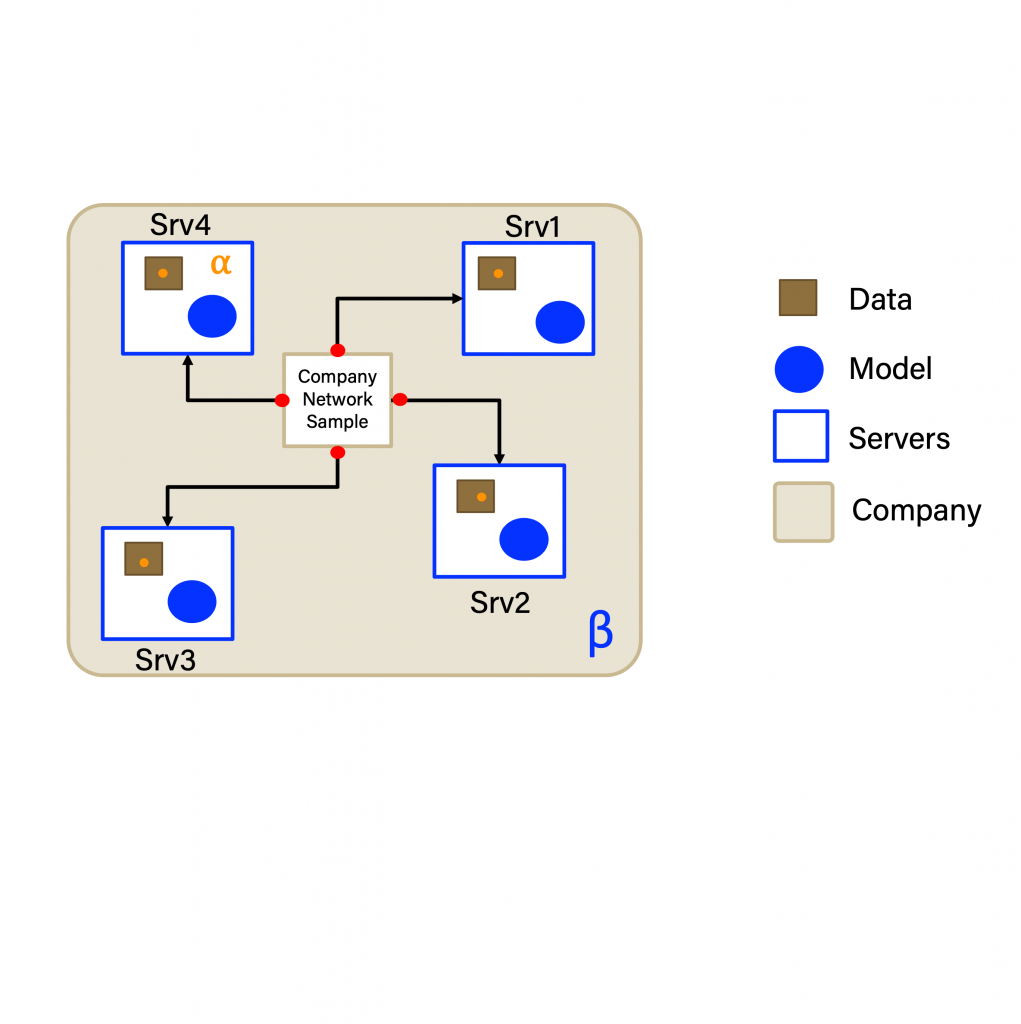
This project studied distributed machine learning in a system-of-systems context, modeled as collaborating AI companies with different data and network roles.
- Analyzed the effect of topology and data diversity on model quality.
- Implemented a three-phase process: local training, parameter sharing, and aggregation.
- Observed links between node centrality and model accuracy variance.
Completed as part of Systems of Systems (AAE56000) at Purdue University.
 2019-22
Morazan Project - the 1st Central American satellite built through regional collaboration
Morazan Project - the 1st Central American satellite built through regional collaboration
Led planning, requirements, and technical coordination for a regional satellite effort across space and ground segments.
- Coordinated internal and external stakeholders including JAXA and UNOOSA.
- Defined around 200 mission, system, and subsystem requirements.
- Implemented secure cloud documentation workflows and mentored subsystem teams.
 2018-19
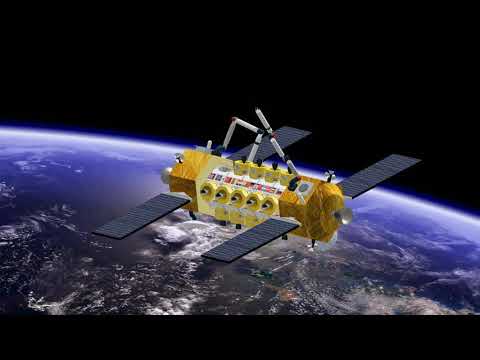
Reusable Space Station mission concept for active debris removal in low Earth orbit
Reusable Space Station mission concept for active debris removal in low Earth orbit
Developed during the ISU Space Studies Program (ESA sponsored), this mission concept addressed active debris removal with eco-design and concurrent engineering principles.
- Developed a Phase-0 design for a robotic manipulator concept.
- Contributed CAD representations for station-level mission architecture.
- Led development of a feasible business case for sun-synchronous debris removal.
 2016-17
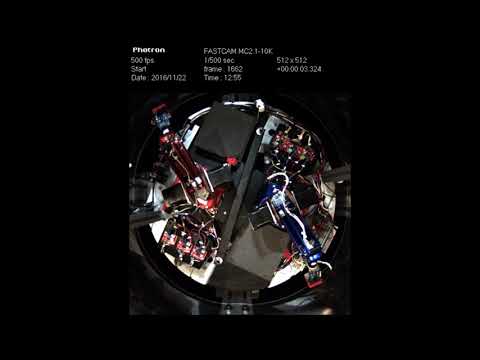
Effect of non-inertial forces over two robotic arms under reduced (artificial) gravity
Effect of non-inertial forces over two robotic arms under reduced (artificial) gravity
After winning the 3rd UNOOSA DropTES cycle, this project executed robotics experiments under microgravity and rotation-induced gravity conditions at ZARM.
- Led a multidisciplinary five-person team under strict technical and schedule constraints.
- Designed and ran a robotic-arm experiment at the Center of Applied Space Technology and Microgravity.
- Presented resulting dynamics analysis at the International Astronautical Congress in Adelaide.
 2016-17
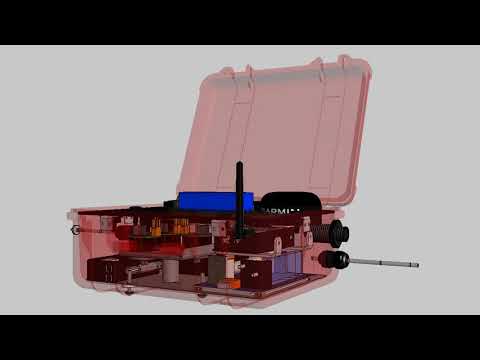
MultiGAS - autonomous remote volcanic gas monitoring station
MultiGAS - autonomous remote volcanic gas monitoring station
Designed, built, validated, and deployed an autonomous gas monitoring station for harsh volcanic environments.
- System measured CO2, H2S, O2, H2, water vapor, temperature, and pressure.
- Combined solar and wind power for multi-year autonomous operation.
- Enabled telemetry over distances above 40 km.
 2015-16
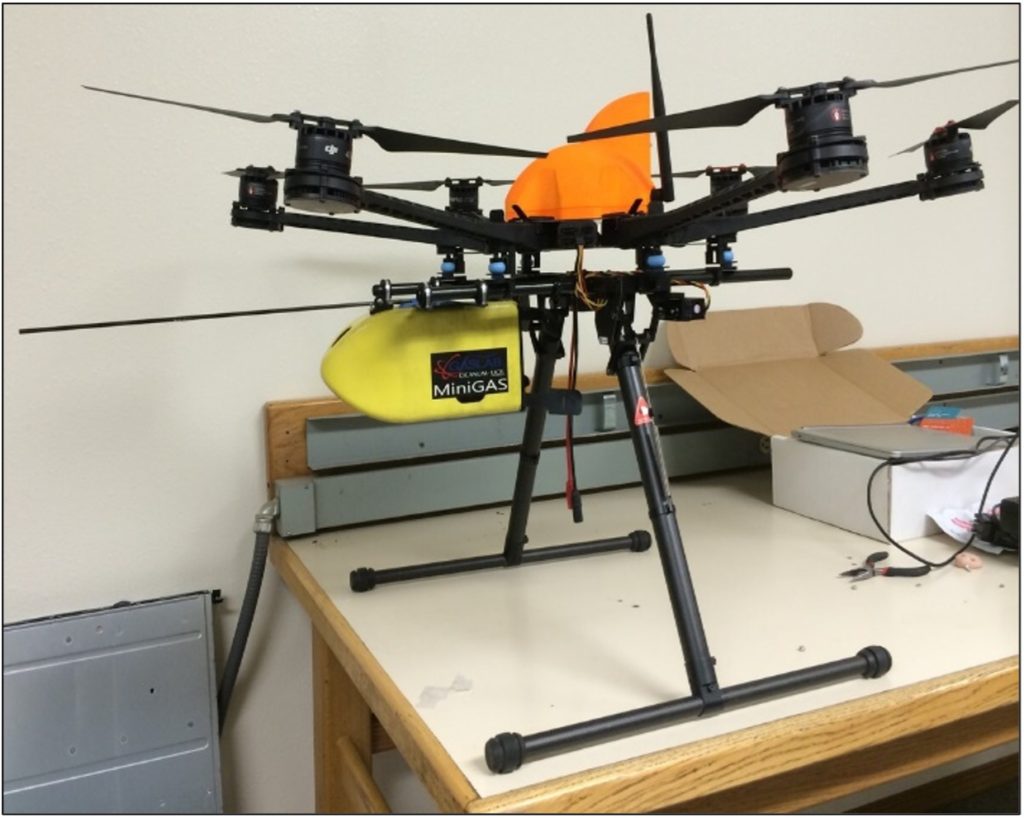
MINIGAS LITE - airborne volcanic activity monitoring system
MINIGAS LITE - airborne volcanic activity monitoring system
Airborne gas-monitoring platform tested at Kilauea with RF telemetry integration.
- Designed PCB integration of CO2, SO2, and H2S sensors on STM32-F4.
- Built radiosonde telemetry chain using Arduino and iMet-1 RSB hardware.
- Validated stratospheric balloon deployment workflow for volcanic measurement.
 2016
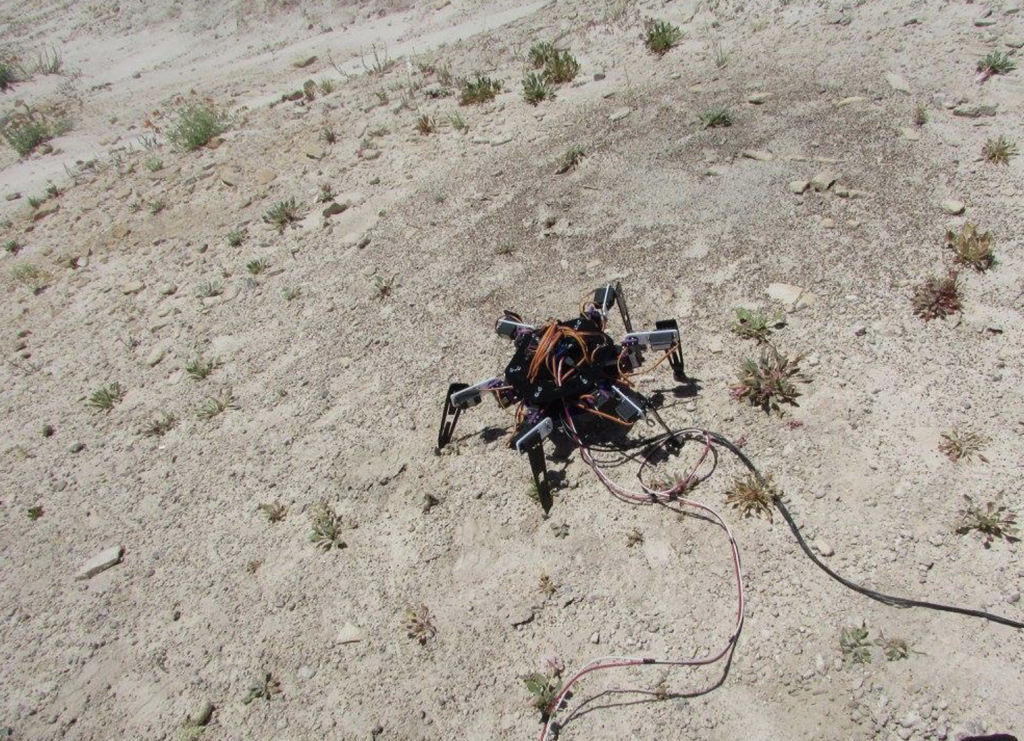
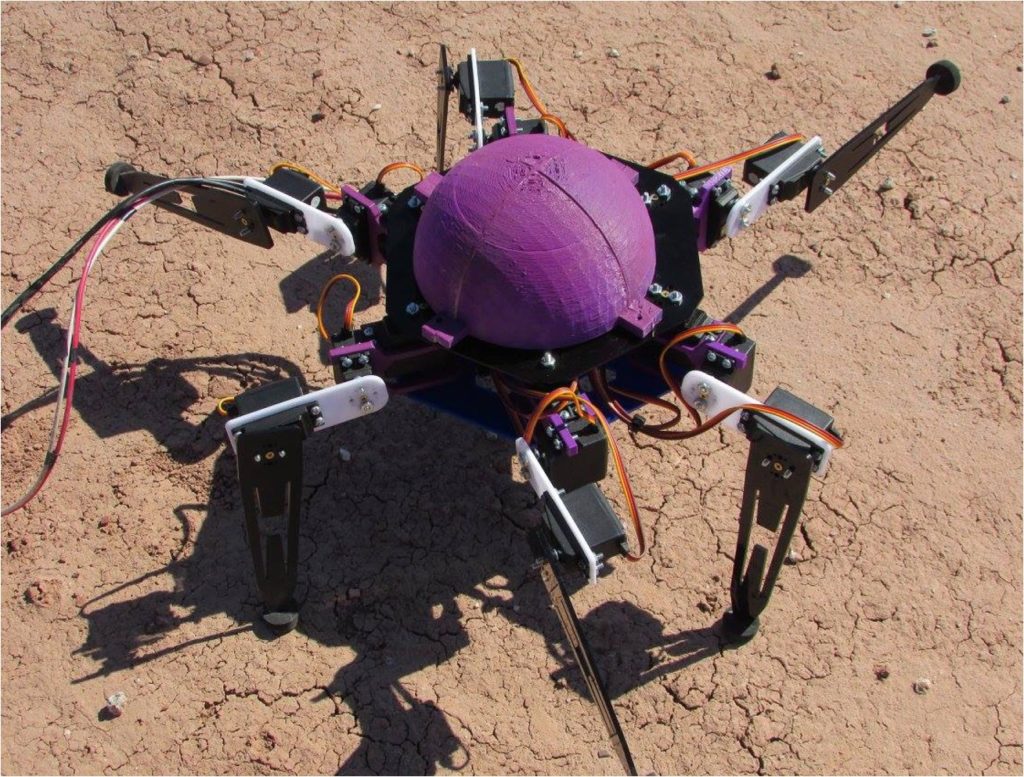
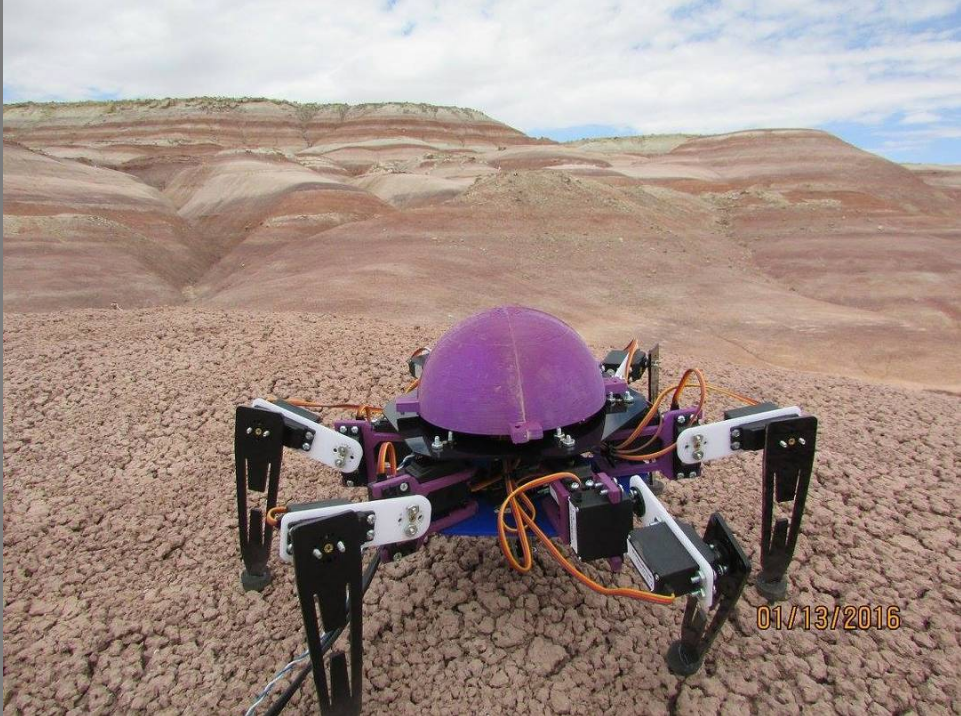
Hexapod Robot Based on Arthropod Locomotion for Difficult Exploration Areas on Mars
Hexapod Robot Based on Arthropod Locomotion for Difficult Exploration Areas on Mars
Project from the first all-Latin-American MDRS analog mission focused on robust rover locomotion concepts.
- Designed, integrated, and tested the hexapod mechanical structure.
- Used iterative engineering optimization and additive manufacturing methods.
 2015
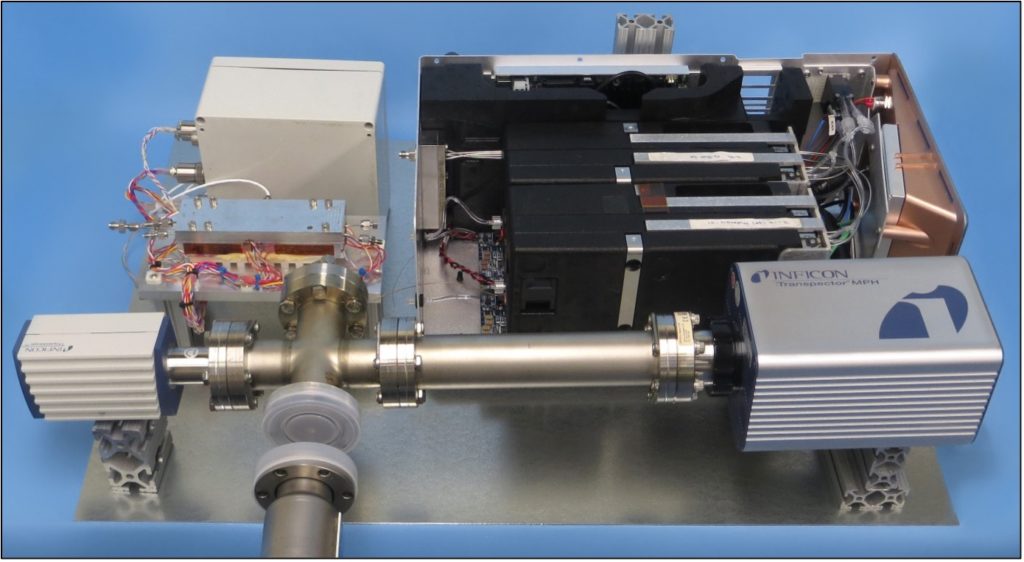
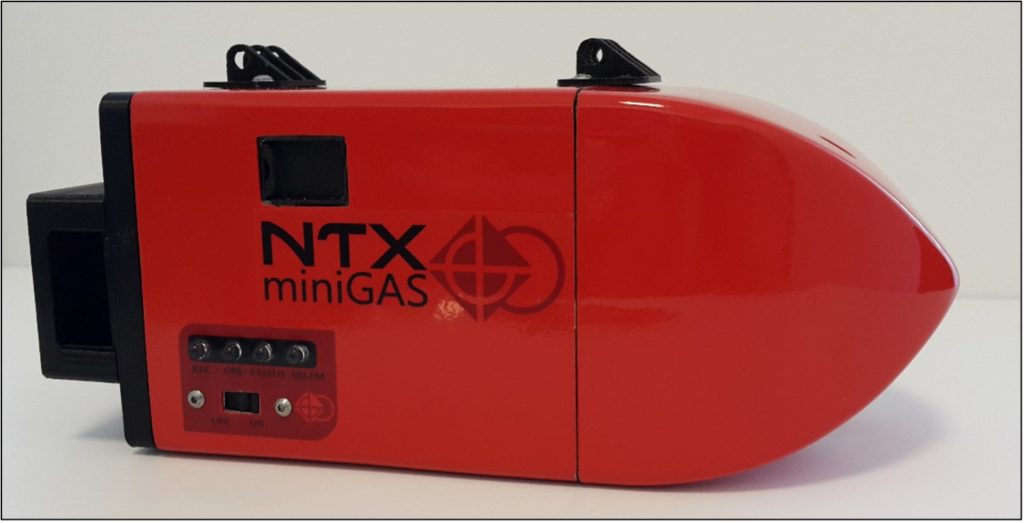
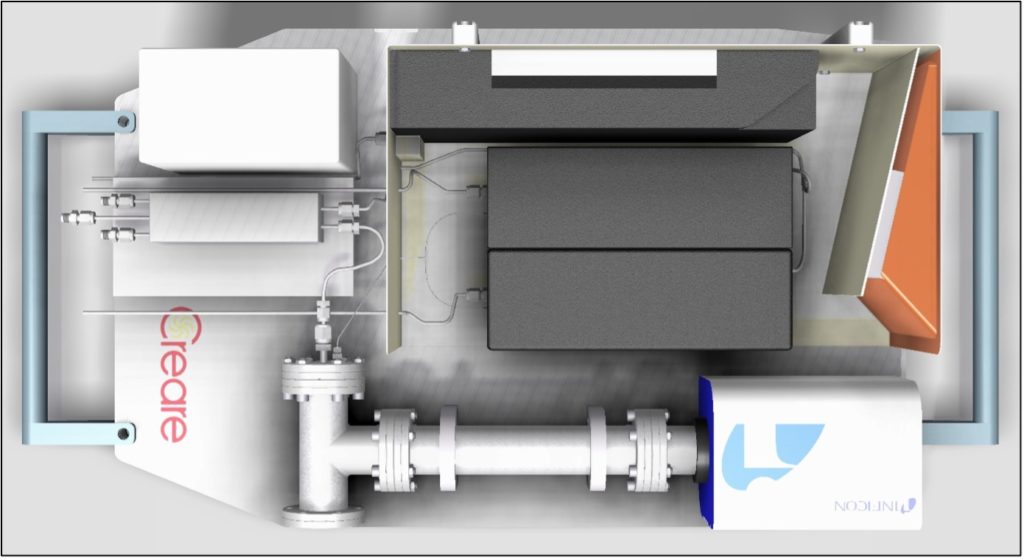
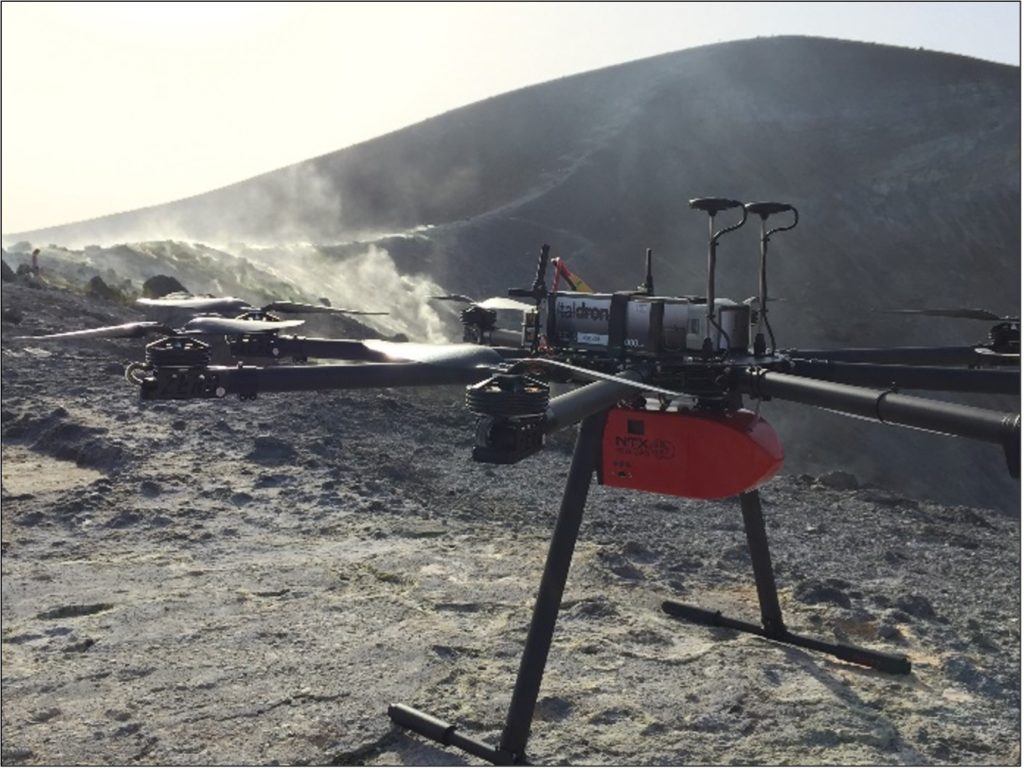
In-flight control unit for a mass spectrometer and subsystems
In-flight control unit for a mass spectrometer and subsystems
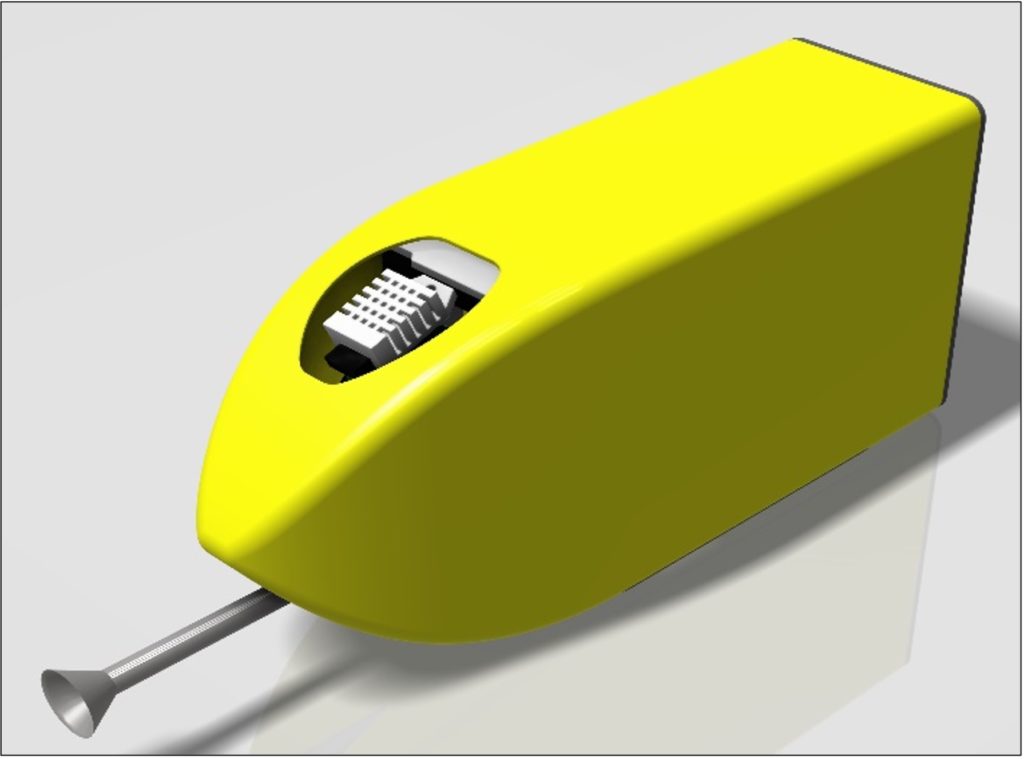
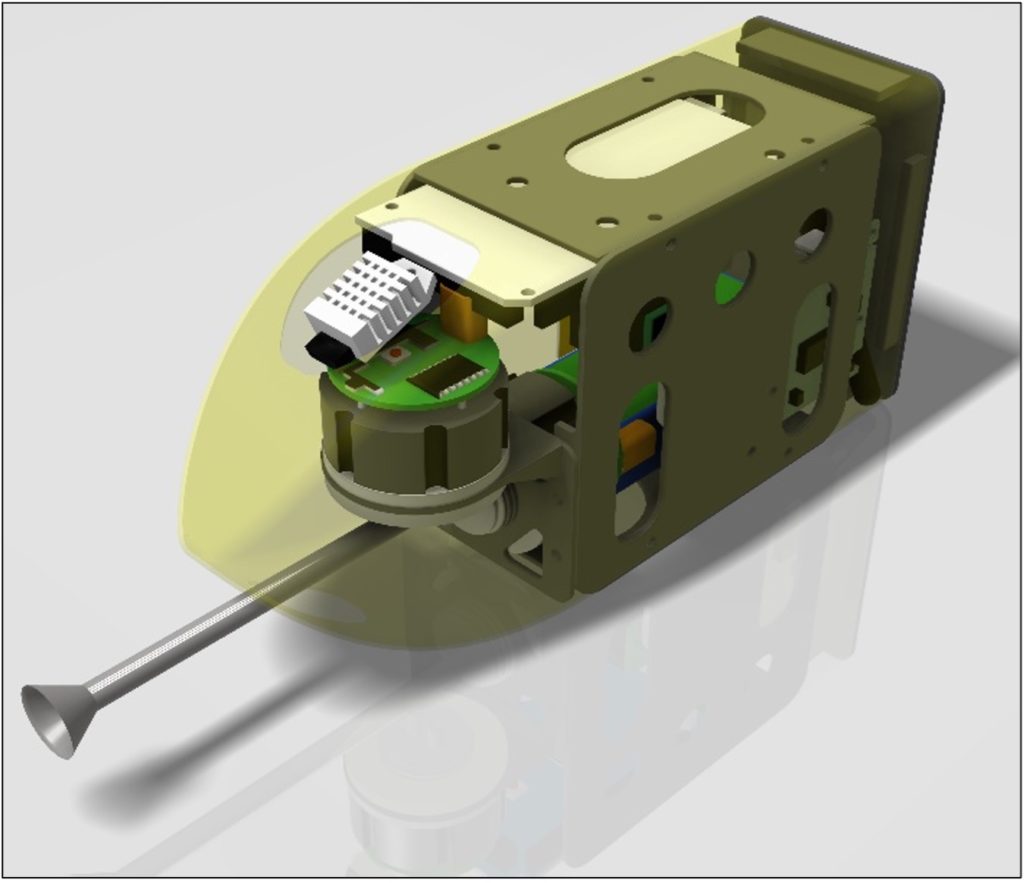
Designed and programmed an ATmega-based in-flight control unit for volcanic research instrumentation.
- Enabled manual and automatic operation of mass spectrometer subsystems.
- Integrated sensing for temperature, humidity, pressure, and airflow.
- Managed turbomolecular pump control and mission power distribution.
 2015-16
Controller box for auto/manual control of hydraulic and pneumatic circuits
Controller box for auto/manual control of hydraulic and pneumatic circuits
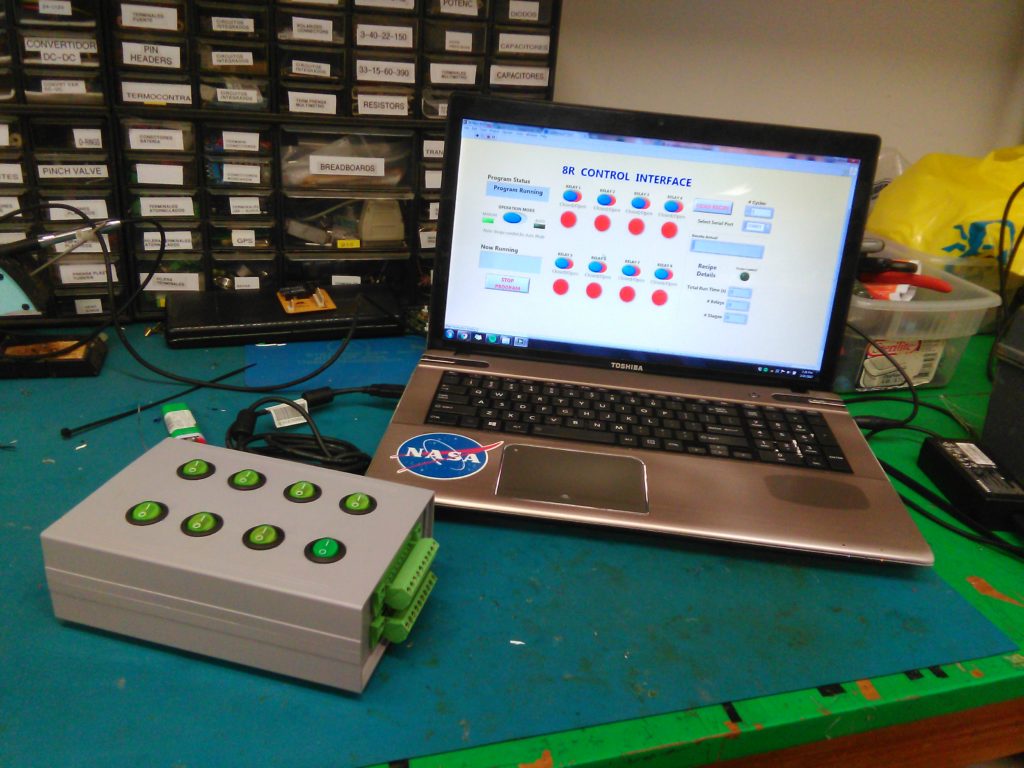
Developed a multipurpose relay-output module for laboratory hydraulic and pneumatic systems with programmable automation.
- Integrated LabVIEW user interface for setup and operation.
- Supported unattended multi-day autonomous operation.
 2014
Blink-controlled small prototype of a remote-controlled car
Blink-controlled small prototype of a remote-controlled car
Designed a prototype remote-controlled car driven by EEG activity and blink-based input.
- Processed real-time EEG with Fourier transforms for mental state detection.
- Implemented control logic for blink-triggered vehicle operation.
- Inspired assistive-technology spinoffs for children with physical disabilities.
 2015
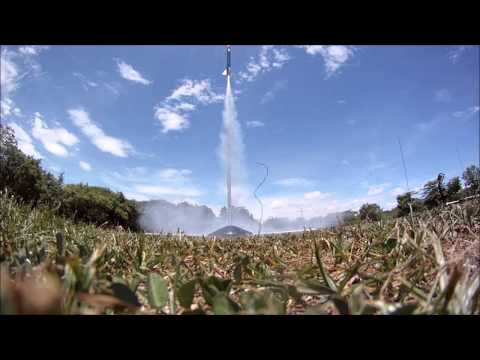
Launch of the first solid-state rocket with a scientific payload in Costa Rica
Launch of the first solid-state rocket with a scientific payload in Costa Rica
Participated in launching a scientific payload mission to measure atmospheric variables in Costa Rica.